103 products
| Image | Model / Name | Weight | Resolution | Output Type | Response Delay | Measuring Range | No-load Current | Contact Capacity | Housing Material | Connection Method | Operating Voltage | Protection Circuit | Storage Temperature | Measurement Accuracy | Transducer Frequency | Dead Zone(Blind Zone) | Operating Temperature | Communication Protocol | Repeatability Accuracy | Protection Rating(IP Rating) | Display | Battery Type | Power Switch | Product Name | Battery Voltage | Input Interface | Mounting Method | Operation Method | Output Interface | Power Supply Source | Number of Transducers | Transducer Cable Length | Continuous Operating Time | Ultrasonic Transducer Type | Accuracy | Material | Beam Angle | Startup Delay | Output Cable Length | Dead Zone (Blind Zone) | Rated Operating Current | Output Connection Method | Protection Rating (IP Rating) | Fastest Response Time (Active Upload) | Buoyancy | Power Supply | Communication | Interface Type | Operating Mode | Number of Beams | Ambient Temperature | Standard | Sensing Range | Output Connection Type | Sensor Mounting Thread | Rated Operating Current Ie | Flange | Frequency | Cable Length | Configurable | Analog Output | Digital Output | Supply Voltage | Average Current | Operating Pressure | Half-Power Beam Angle | Power | Detection Range | Weight (Direct Cable Outlet) | Name | Response Time | Applicable Media | Probe Cable | Voltage Drop | Accessories Weight | Protection Rating (IP Rating)_2 | Weight of Aviation Connector Version | Fastest Response Speed in Active Upload Mode | Accessory Weight | Output Connection | Fastest Response Time | No-Load Current | Transducer Frequency_2 | Operating Temperature_2 | Weight (Aviation Connector Version) | Applicable Medium | Dead Zone (Blind Zone) Distance | Response Speed | Accuracy Standard | Measurement Frequency | Measuring Range Options | Rated Current | Model | Communication Interface |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
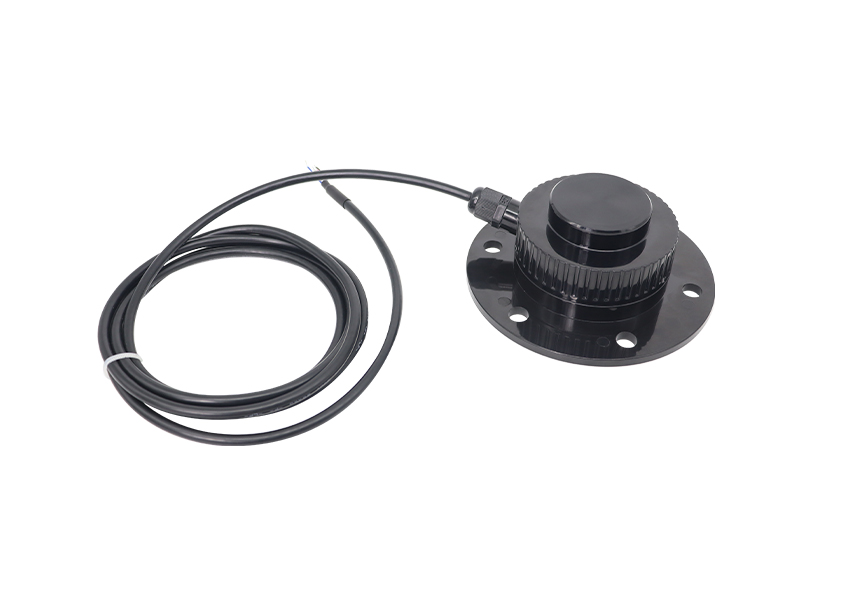 | PCM80 Ultrasonic Ranging Sensor PCM80 | 370g g | 0.001m m | 1 SPST (Single Pole Single Throw) Relay | ≤300ms ms | 0.25~3.5m m | ≤25mA mA | DC28V/5A (Default State: Normally Open) | ABS | Six-core Cable, 2m | 24V±10% V | Reverse Polarity Protection, Transient Overvoltage Protection | -40℃~+80℃ ℃ | ±0.03m or ±0.5% FS (whichever is greater) | 64kHz±5% kHz | 0.25m m | -20℃~+60℃ ℃ | Modbus RTU Protocol | ±0.25% FS % FS | IP68 | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
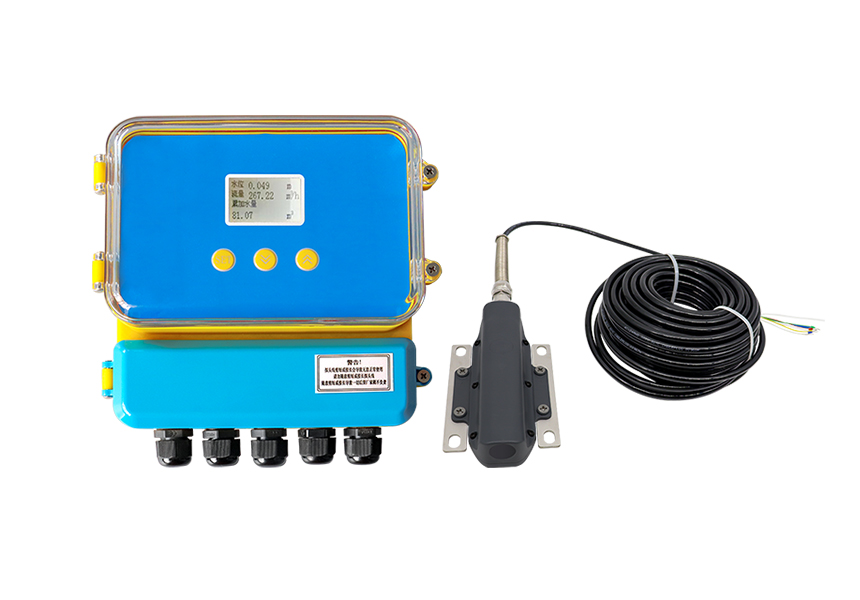 | Ultrasonic Doppler Flow Meter Ultrasonic Doppler flowmeter | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
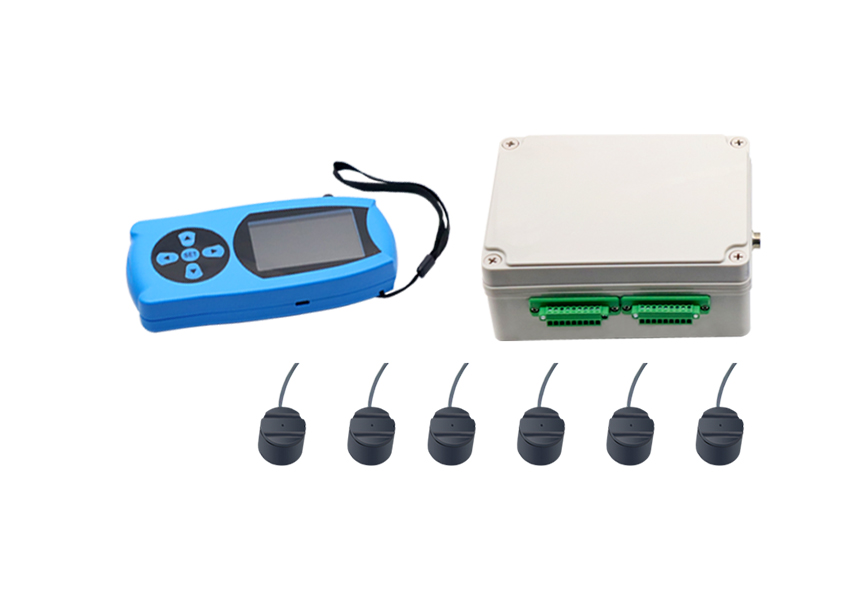 | Ultrasonic Tree Inspection Sensor (measures holes, cracks, defects, etc. inside trees) Ultrasonic tree inspection sensor (for measuring internal holes, cracks, defects, etc. in trees) | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | IP54 | Color LCD with Backlight | Rechargeable Lithium Battery | Built-in | Ultrasonic Tree Measurement Sensor | 3.6V V | 1 channel | Clamp or Strap Mounting | Push Buttons | None | Built-in Battery | 6 pcs | 2.0 m | 3 hours 40 minutes | Tree Detection Transducer | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
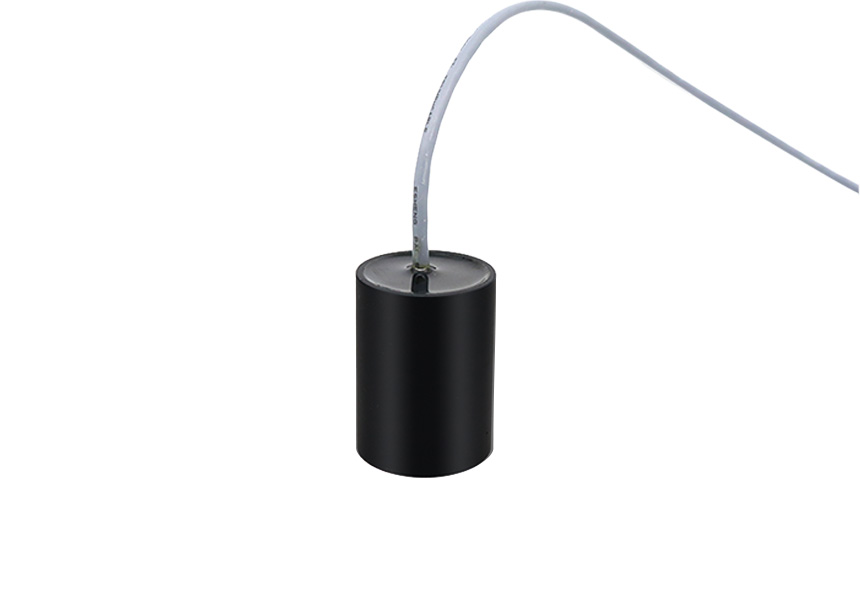 | M36 Underwater Obstacle Avoidance Sensor (Customized Version) M36 | — | — | RS-485 (Modbus RTU Protocol) | — | 0.3~20m 0.4~50m 0.1~8m 0.05~3m m | — | — | — | — | 10.8V~26.4VDC, Reverse Polarity Protection VDC | — | -20~60°C °C | — | 300K 300K 1MHz 2MHz | — | -20~60°C °C | — | ±0.25% % | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 0.02m±0.5%D (D refers to the measured depth) | ABS | 19.4°±1.9° 10°±1° 4.6°±0.5° 2.1°±0.5° ° | <2000ms (Software delay for protection) ms | Default 2m (Other cable lengths require customization) m | 0.3m 0.4m 0.1m 0.05m m | ≤100mA mA | 4-core Cable Output | IP68 (Pressure resistant to 150m) | 140ms/time 300ms/time 115ms/time 110ms/time ms/time | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
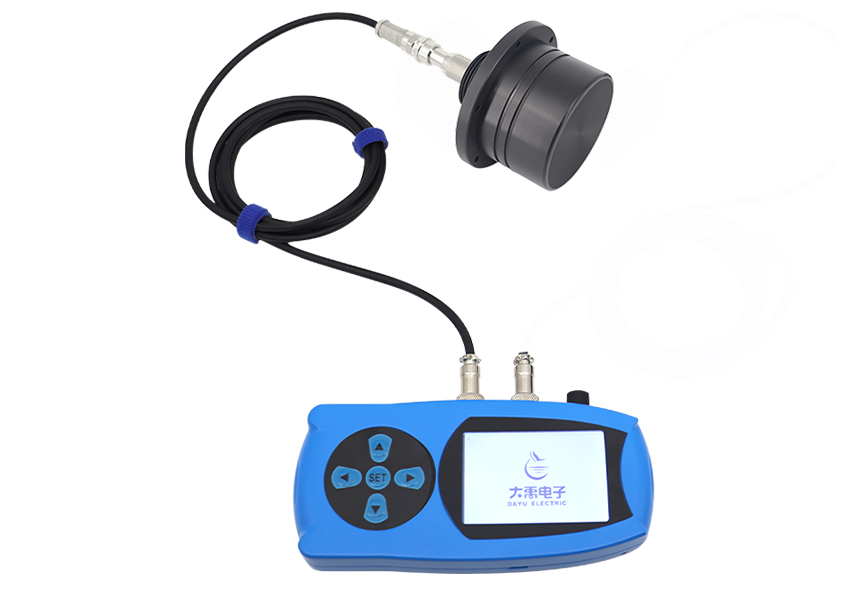 | Handheld Depth Sounder Handheld depth sounder | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
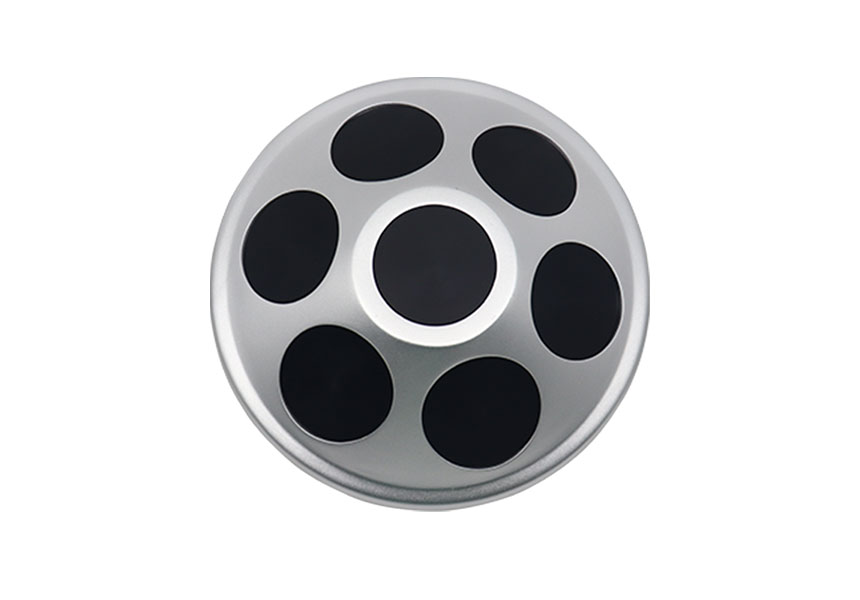 | 3D Point Fish Sonar(Large Volume) 3D point fish sonar (large volume) | — | — | — | — | Maximum 25 m m | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | IP68 | — | Self-floating | 10.8 VDC ~ 26 VDC VDC | RS485 communication, ModBus RTU protocol | RS485 | Self-transmitting and self-receiving | 7 beams beams | -20℃~60℃ ℃ | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
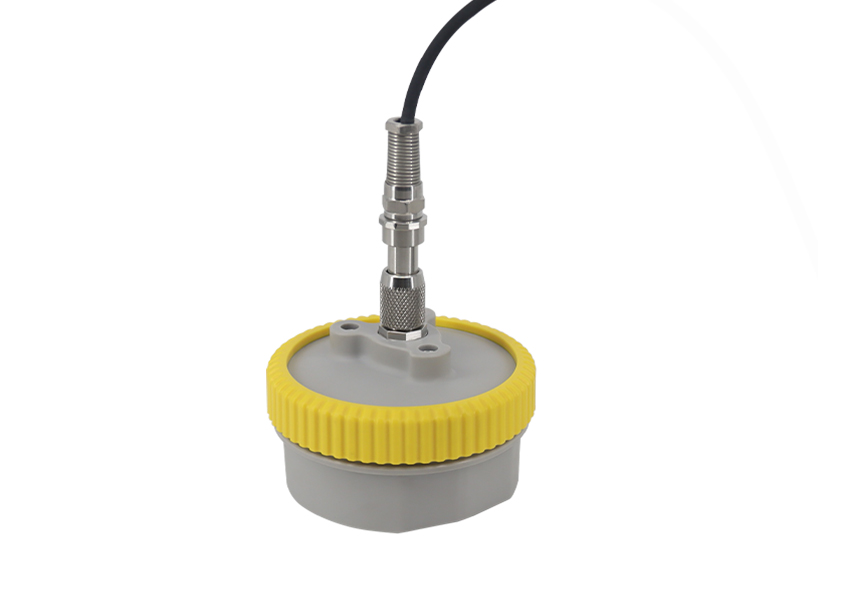 | 8 Beam Underwater Obstacle Avoidance Sensor Eight-beam underwater obstacle avoidance sensor | 400g g | — | Standard RS-485 (Modbus RTU protocol), TTL output optional | — | — | — | — | — | — | 10.8VDC~26.4VDC, reverse polarity protection VDC | — | -20~+60℃ ℃ | 0.01m±0.5%D (D refers to the measured range) | 400kHz±5% kHz | — | -20~+60℃ ℃ | — | 0.25%D (D refers to the measured range) %D | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | PC+ABS | — | ≤1000ms ms | — | <0.2m m | — | — | Sensor: IP68 (pressure resistant to 150m) | — | — | — | — | — | — | — | — | GB/T 14048.10-2016 | 0.2~10m m | GX12 4-pin connector (aviation plug connection) | M6*20 (length adjusted according to the bracket) | ≤60mA (24V) mA | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
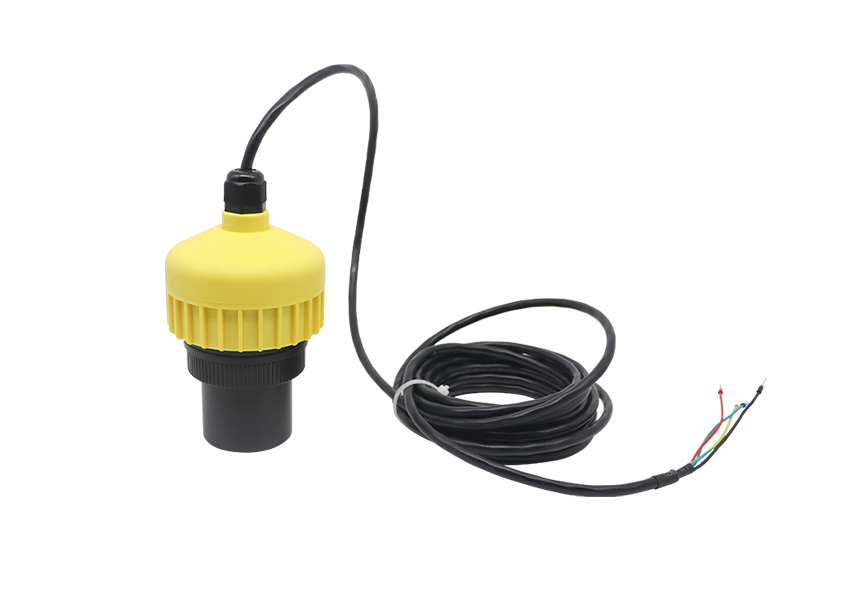 | IP68 ultrasonic water level meter(10-28V power supply,ABS material) IP68 | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
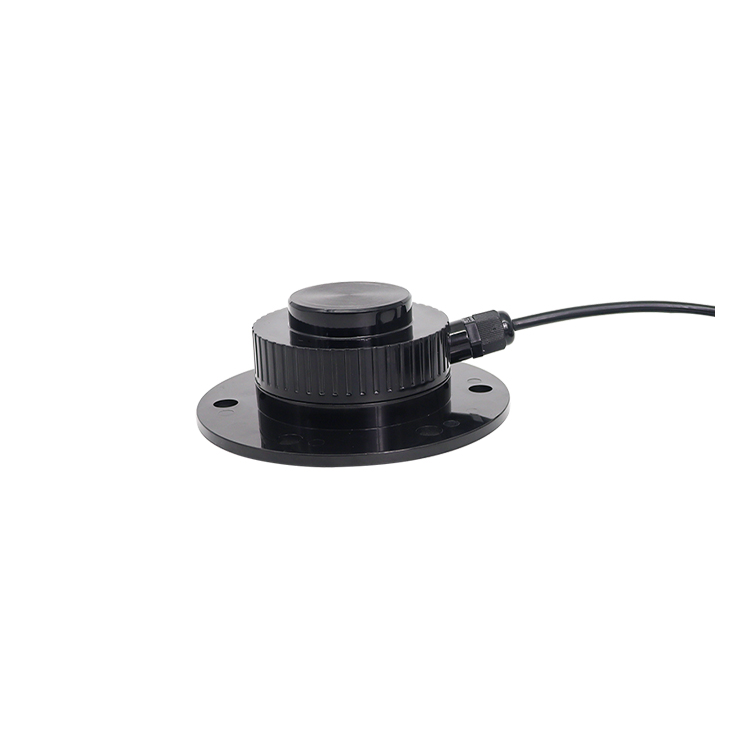 | PCM80 micro-power ultrasonic water level meter PCM80 | ≤500g g | — | — | — | 0.25~3.5m m | — | — | ABS | — | — | — | -40~+80℃ ℃ | — | — | — | -20~+60℃ ℃ | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | ±0.5%FS or ±0.03m (whichever is greater) | — | 64kHz (14°±5%) ° | — | — | — | — | — | IP68 | — | — | — | — | — | — | — | — | — | — | — | — | — | Non-standard | 64kHz kHz | Standard 2m (not recommended to exceed 2m; the shorter the better) m | Built-in BLE Bluetooth | 0.1V~2.6V (for direct MCU sampling) V | Standard RS-485 or optional 3.3V LVTTL (Modbus RTU protocol) | 3VDC~5VDC VDC | ≤3mA/3.6V (instantaneous current 7mA/3.6V) mA | 1 standard atmosphere atm | 64kHz (6°±5%) ° | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
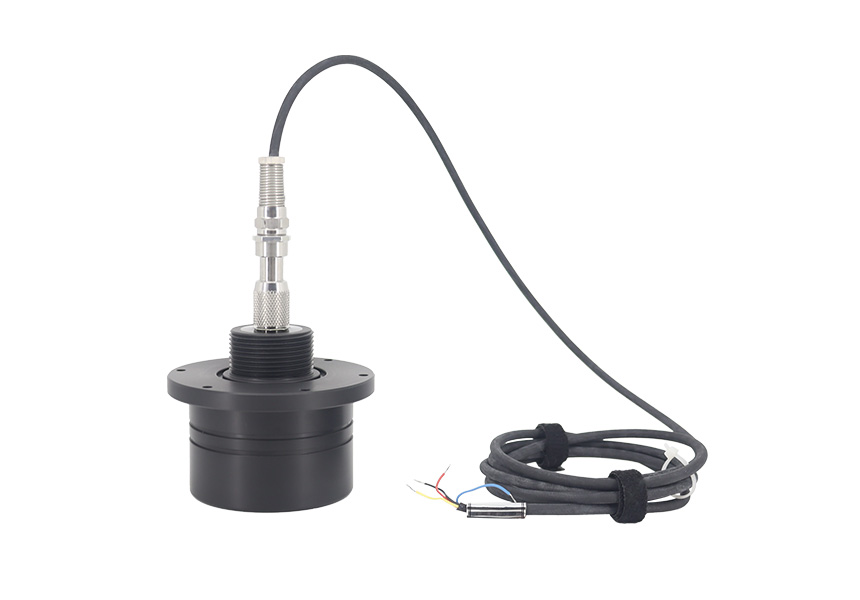 | M80 underwater obstacle avoidance sensor(ABS housing, with aviation plug) M80 | — | — | RS-485 (Modbus RTU Protocol) | — | — | — | — | — | — | 10.8V~26.4VDC, Reverse Polarity Protection VDC | — | -20~+60°C °C | — | 200K (Long Range) | 88K | 0.4m | 0.5m m | -20~+60°C °C | — | 0.25%D (D refers to the measured range) %D | IP68 (Pressure resistance 150m) | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 0.02±0.5%D (D refers to the measured range) | ABS | 8.7°±0.9% | 16.5°±10% | <2000ms (Software delay for protection) ms | Default 5m (Other cable lengths require customization) m | — | — | 4-core cable outlet / Aviation connector outlet | — | 50~65535ms / cycle (Adjustable) | 50~65535ms / cycle (Adjustable) ms | — | — | — | — | — | — | — | — | — | — | — | ≤100mA mA | — | — | — | — | — | — | — | — | — | — | ≤1W W | 0.4~200m | 0.5~300m m | 576g (5m cable) | 1480g (5m aviation connector) g | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
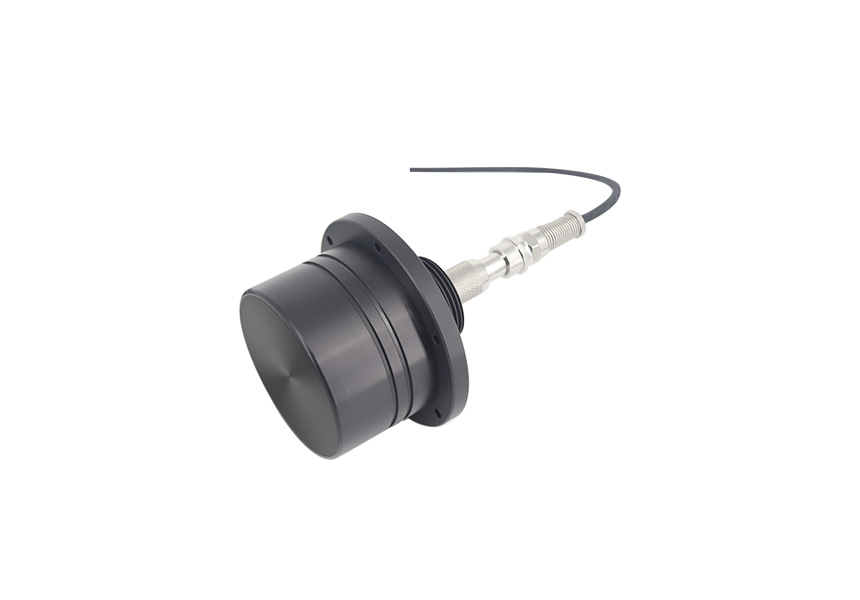 | M80 depth sounder(ABS housing, with aviation connector) M80 | — | — | Modbus-RTU Protocol | — | 50/100/200/300 m m | — | — | ABS | — | — | — | — | — | — | 0.5-1.0 m m | — | — | — | IP68 | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 2cm±0.5%D | — | 5.7°~16.5° ° | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 10.8-26.4V V | — | — | — | — | — | — | M80 Depth Sounder | 250-900ms ms | Clean Water, Muddy Water, Fresh Water, Seawater | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
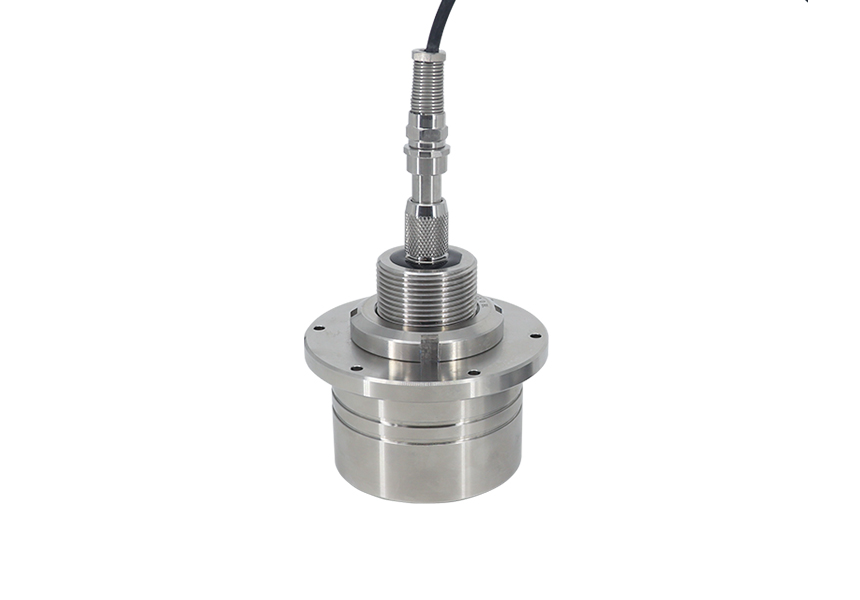 | M80 underwater obstacle avoidance sensor(304 housing, with aviation connector) M80 | — | — | Standard RS485 output (Modbus-RTU protocol) | — | 50m 100m 200m 300m m | ≤15mA mA | — | Three types: ABS, 304 stainless steel, 316 stainless steel | — | 10.8~26.4V, reverse polarity protection V | — | — | — | 300KHz 300KHz 300KHz 300KHz | — | -20~+60℃ ℃ | — | — | — | — | — | — | M80 Underwater Obstacle Avoidance Sensor | — | — | — | — | — | — | — | — | — | — | — | — | 5.7°±0.6° 8.7°±0.9° 8.7°±0.9° 16.5°±1.7° ° | <2000mS (software delay used as protection; final version TBD) mS | Default 5m (other lengths require customization) m | 0.50m 0.70m 0.85m 1.00m m | ≤100mA, short-circuit/overload protection mA | 4-core cable outlet / aviation connector outlet | IP68 at 100m water depth | — | — | — | — | Aviation connector or direct cable outlet | — | — | -20℃ < C < 60℃ ℃ | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | Approx. 542g Approx. 576g Approx. 576g Approx. 710g (with 5m cable) g | — | — | — | 4-core industrial cable | ≤1.5V V | 3 washers + 1 ABS nut, 93g in total g | IP68, pressure resistant to 150m | 88KHz: 630g; 200KHz: 477g; 300KHz: 440g; g | 250ms/time 290ms/time 590ms/time 900ms/time | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
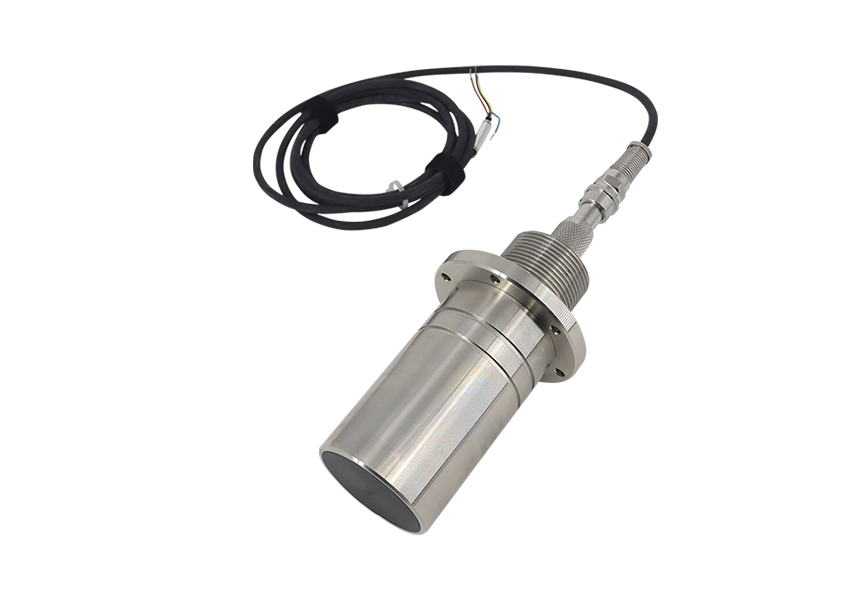 | M50 underwater obstacle avoidance sensor(304 housing, with aviation connector) M50 | 425g (with 5m cable)|463g (with 5m cable)|463g (with 5m cable)|1090g (with 5m aviation plug cable) | — | RS-485 (Modbus RTU protocol) | — | 0.5~50m|0.7~100m|0.4~200m|0.5~100m m | — | — | — | — | — | — | -20~60℃ ℃ | — | 300K|200K|200K(Long Range)|88K | 0.5m|0.7m|0.4m|0.5m m | -20~60℃ ℃ | — | D±0.25% (D refers to the measured range) | IP68 (pressure resistant to 150m) | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 0.02m±0.5%D (D refers to the measured range) | 304 stainless steel | 9.7°±1%|11.8°±1.2%|11.8°±1.2%|27.7°±10% | <2000ms (software delay for protection) ms | 5m by default (other lengths available on request) m | — | ≤100mA mA | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 10.8V~26.4VDC, reverse polarity protection VDC | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | Three washers and one nut, 57g total g | 4-core cable outlet / aviation plug outlet | (Active Upload) 250ms/cycle|290ms/cycle|50~65535ms/cycle (adjustable)|50~65535ms/cycle (adjustable) | — | — | — | — | — | — | — | — | — | — | — | — | — |
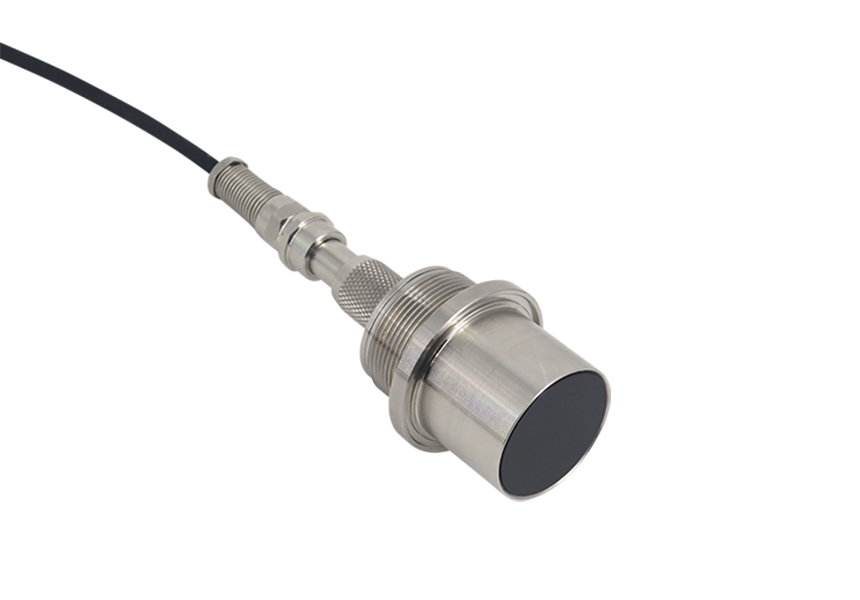 | M36 underwater obstacle avoidance sensor(plus version, 304 housing) M36 | — | — | Standard RS485 Output (Modbus-RTU Protocol) | — | 20m 50m 8m | — | — | Three types: ABS, 304 Stainless Steel, 316 Stainless Steel | — | 10.8~26.4V, Reverse Polarity Protection V | — | — | — | 300KHz 300KHz 1MHz | 0.30m 0.50m 0.05m | -20~+60°C -20~+60°C -20~+60°C °C | — | — | IP68 at 100m Water Depth | — | — | — | M36 Underwater Obstacle Avoidance Sensor | — | — | — | — | — | — | — | — | — | — | — | — | 19.4°±1.9° 10°±1° 4.6°±0.5° | <2000mS (software delay used for protection; final specification TBD) mS | Default 2m (other lengths require customization) m | — | ≤100mA, Short-Circuit/Overload Protection mA | 4-Core Cable Outlet / Aviation Connector Outlet | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | Approx. 151g (2m cable, direct outlet) Approx. 114g (net weight, aviation connector version) Approx. 94g (net weight, aviation connector version) | — | — | — | — | ≤1.5V V | — | — | — | 140ms/cycle 300ms/cycle 115ms/cycle | 3 washers + 1 ABS nut, 57g in total | — | — | ≤15mA mA | 300KHz/1MHz | -20~+60°C °C | 300KHz: 331g; 200KHz: 370g | — | — | — | — | — | — | — | — | — |
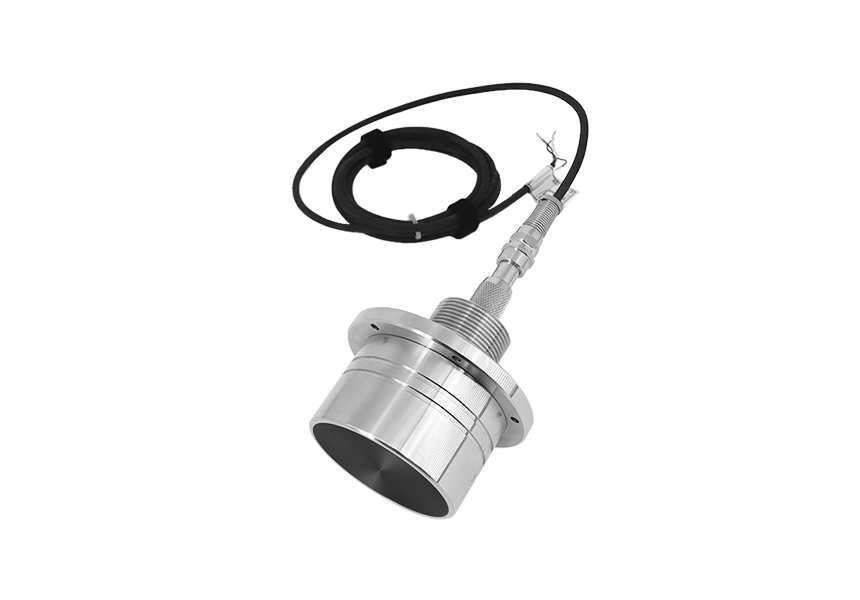 | M80 depth sounder(304 housing, with aviation connector) M80 | — | — | Modbus-RTU Protocol | — | 50/100/200/300 m m | — | — | 304 | — | 10.8-26.4V V | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 2cm±0.5%D | — | 5.7°~16.5° ° | — | — | — | — | — | IP68 rated for 100m water depth | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | M80 Depth Sounder | 250-900ms ms | — | — | — | — | — | — | — | — | — | — | — | — | — | — | Clear water, silt-laden water | 0.5-1.0 m m | — | — | — | — | — | — | — |
 | M36 depth sounder(custom, ABS housing) M36 | 94g ~ 370g g | — | RS485 (Modbus-RTU) | — | 50 m m | — | — | ABS Material | — | — | — | — | — | 300KHz KHz | 0.30 m m | -20~+60℃ ℃ | — | — | 100 m Water Depth IP68 | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 4.6°~ 19.4° ° | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 10.8 ~ 26.4V V | — | — | — | — | — | — | M36 Depth Sounder (Custom Model) | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
 | M50 depth sounder(ABS housing, with aviation plug) M50 | — | — | — | — | — | — | — | ABS | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | RS485 digital signal | — | — | — | — | — | — | — | 9.7°±1° narrow beam ° | — | — | — | — | — | IP68 at 100 m water depth | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 10.8-26.4V DC V | — | — | — | — | — | — | M50 Depth Sounder | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | Only 0.5 m / 0.7 m | As fast as 250ms per cycle ms | ±2cm±0.5%D | 300KHz/200KHz optional | Dual specifications: 50 m / 100 m | — | — | — |
 | M50 underwater obstacle avoidance sensor(ABS housing, with aviation plug) M50 | — | — | — | — | — | — | — | ABS Material | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | RS485 Digital Signal | — | — | — | — | — | — | — | 9.7°±1° Narrow Beam ° | — | — | — | — | — | 100 m Water Depth IP68 | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | 10.8-26.4V DC V | — | — | — | — | — | — | M50 Underwater Obstacle Avoidance Sensor | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | Only 0.5 m / 0.7 m m | Up to 250ms per Measurement ms | ±2cm±0.5%D | 300KHz/200KHz Optional KHz | 50 m / 100 m Dual Specifications m | — | — | — |
 | M50 depth sounder(304 housing, with aviation plug) M50 | — | — | Standard RS485 output (Modbus-RTU protocol) | — | 50 ~ 100 m m | ≤15mA mA | — | Stainless steel housing | 4-core cable outlet / aviation connector outlet | 10.8 ~ 26.4V, reverse polarity protection V | — | — | — | 300KHz/200KHz frequency KHz | — | -20 ~ 60℃ ℃ | — | — | — | — | — | — | M50 Depth Sounder | — | — | — | — | — | — | — | — | — | — | ±0.25% accuracy % | — | 9.7°~11.8° beam angle ° | — | — | 0.50 m m | — | — | IP68 waterproof | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | ≤100mA, short-circuit / overload protection mA | — | — |
 | M36 depth sounder (plus model, ABS housing) M36 | 94g~370g g | — | RS485 (Modbus-RTU) | — | 8 m / 20 m / 50 m m | — | — | 304 Stainless Steel | — | 10.8~26.4V V | — | — | — | 300KHz/1MHz | 0.05 m / 0.30 m / 0.50 m m | -20~+60℃ ℃ | — | — | IP68, 100 m water depth | — | — | — | M36 Depth Sounder | — | — | — | — | — | — | — | — | — | — | — | — | 4.6°/10°/19.4° ° | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
 | M36 depth sounder (plus model, 304 stainless steel housing, with aviation plug) M36 | 194g/214g/370g g | — | RS485 (Modbus-RTU) | — | 8 m /20 m /50 m m | — | — | 304 Stainless Steel | — | 10.8~26.4V V | — | — | — | 300KHz/1MHz | 0.05 m /0.30 m /0.50 m m | -20~+60℃ ℃ | — | — | 100 m Water Depth IP68 | — | — | — | M36 Depth Sounder | — | — | — | — | — | — | — | — | — | — | — | — | 4.6°/10°/19.4° ° | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
 | 3D fish-finding sonar(small size)for counting fish school numbers 3D fish-detection sonar (compact) for counting fish school quantity | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |
 | M50 depth sounder(hydrological custom version) M50 | 420g±20g g | — | — | — | 0.4 ~ 50m m | — | — | — | — | 10.8V~26.4VDC VDC | — | — | — | — | — | -20℃~+60℃ ℃ | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | ±2cm (±0.5%D) | 316 Stainless Steel Housing | — | — | — | — | — | — | IP68 | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | M50 Depth Sounder (Hydrological Customization) | ≤250ms ms | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | MEPC50K-M50GM6-C8L | RS485 (Modbus RTU) |
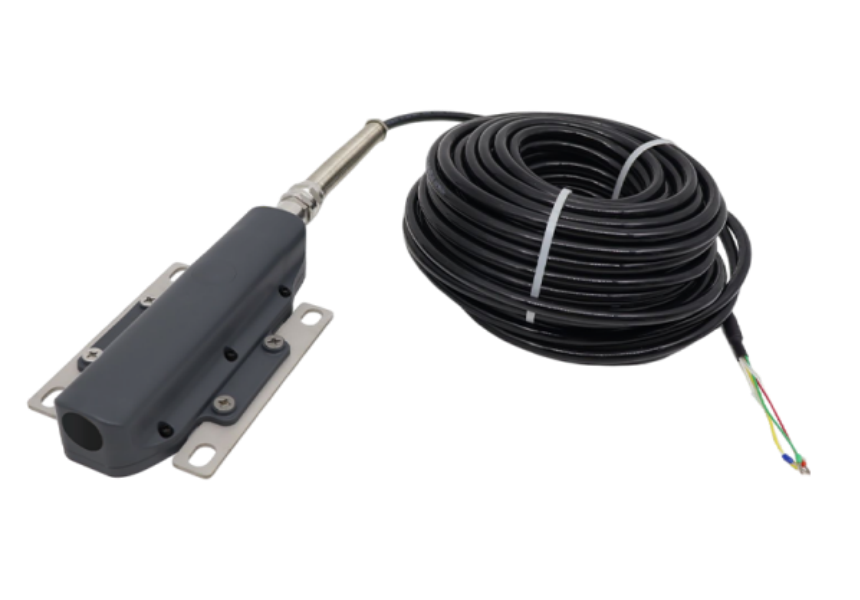 | Small ultrasonic Doppler velocity meter, road drainage monitoring Compact ultrasonic Doppler current meter for road drainage monitoring | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — | — |