Tel: 0591-28082552Mob: 18050180580
👤 Login / Register
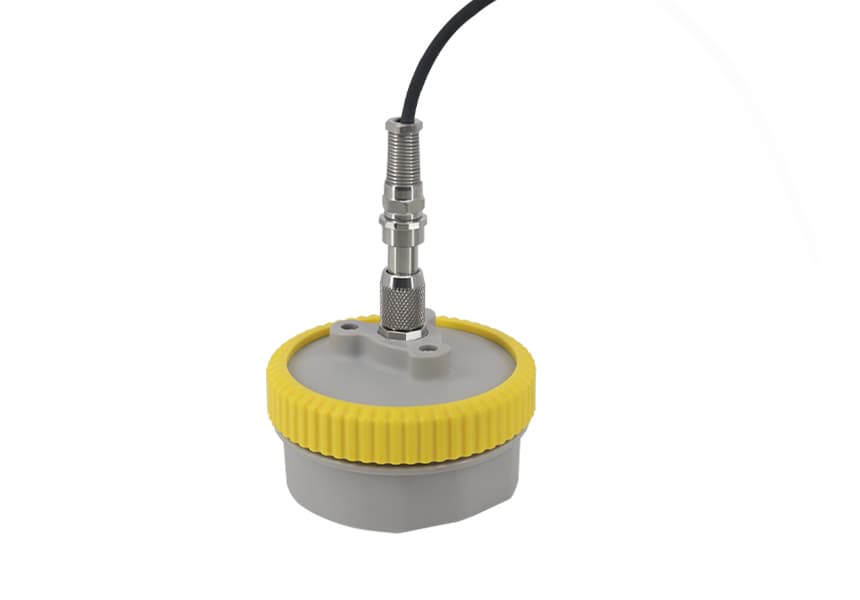
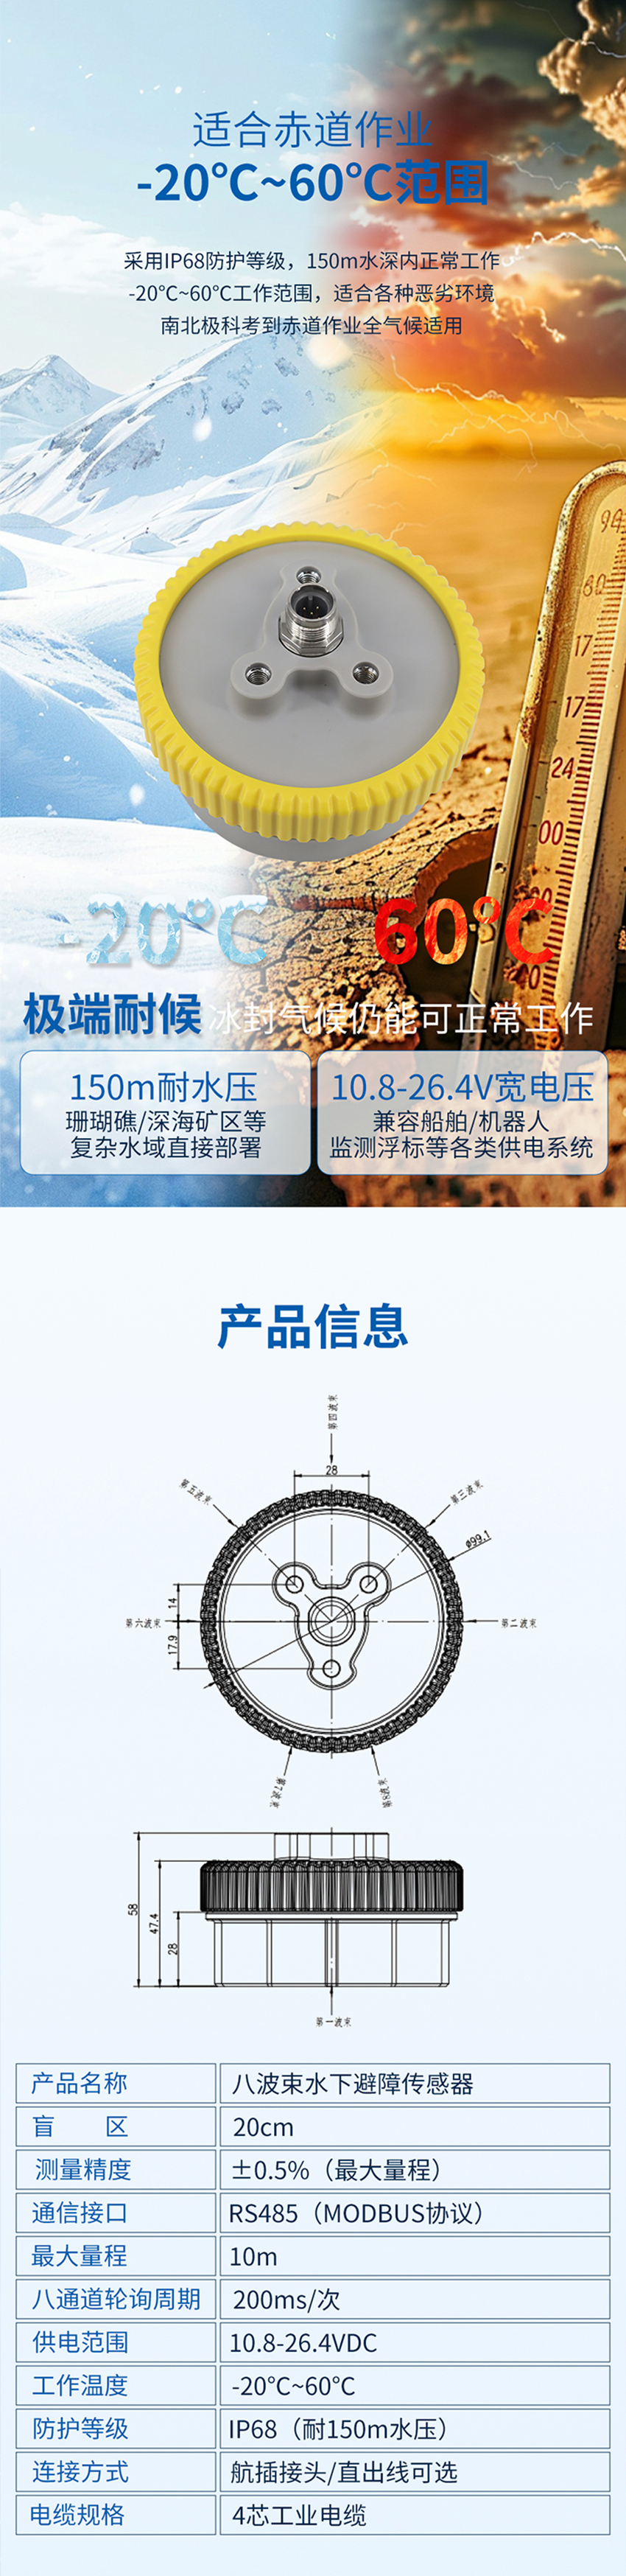
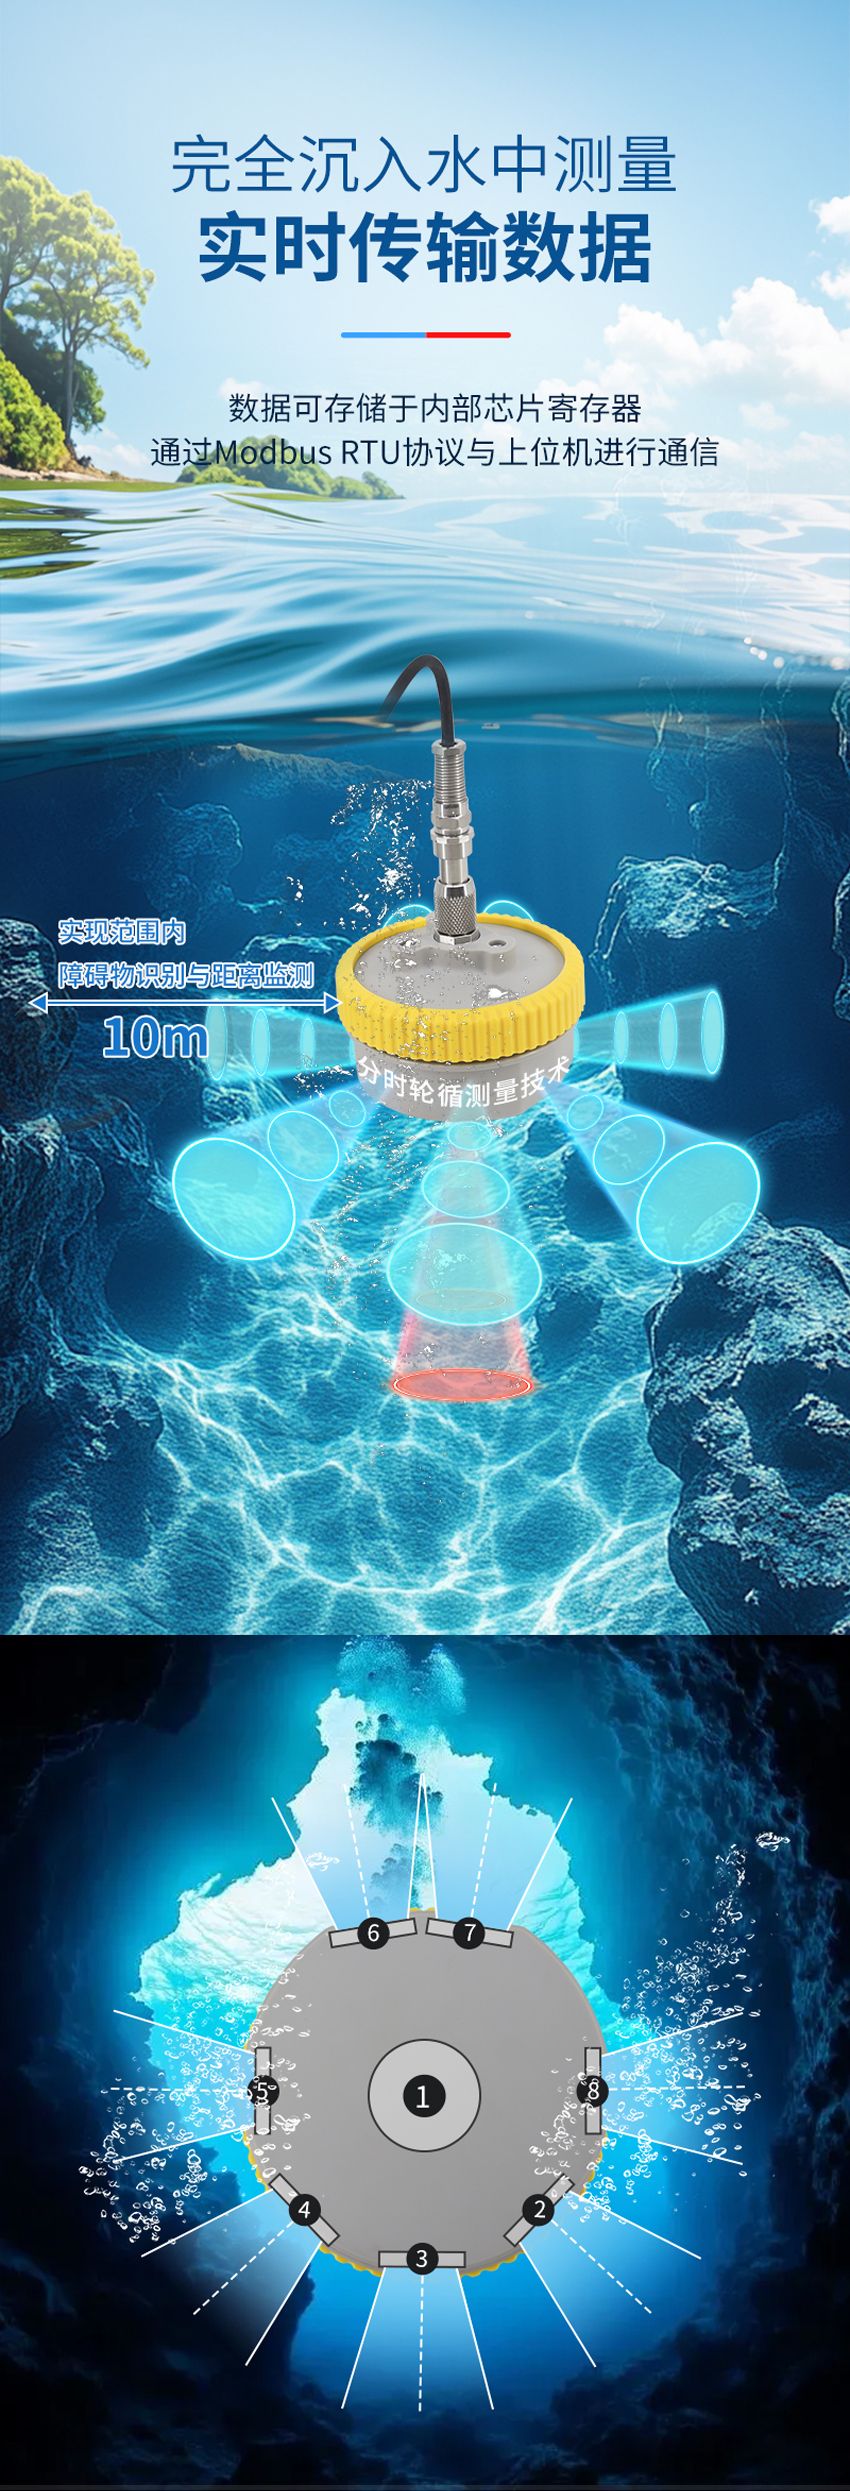
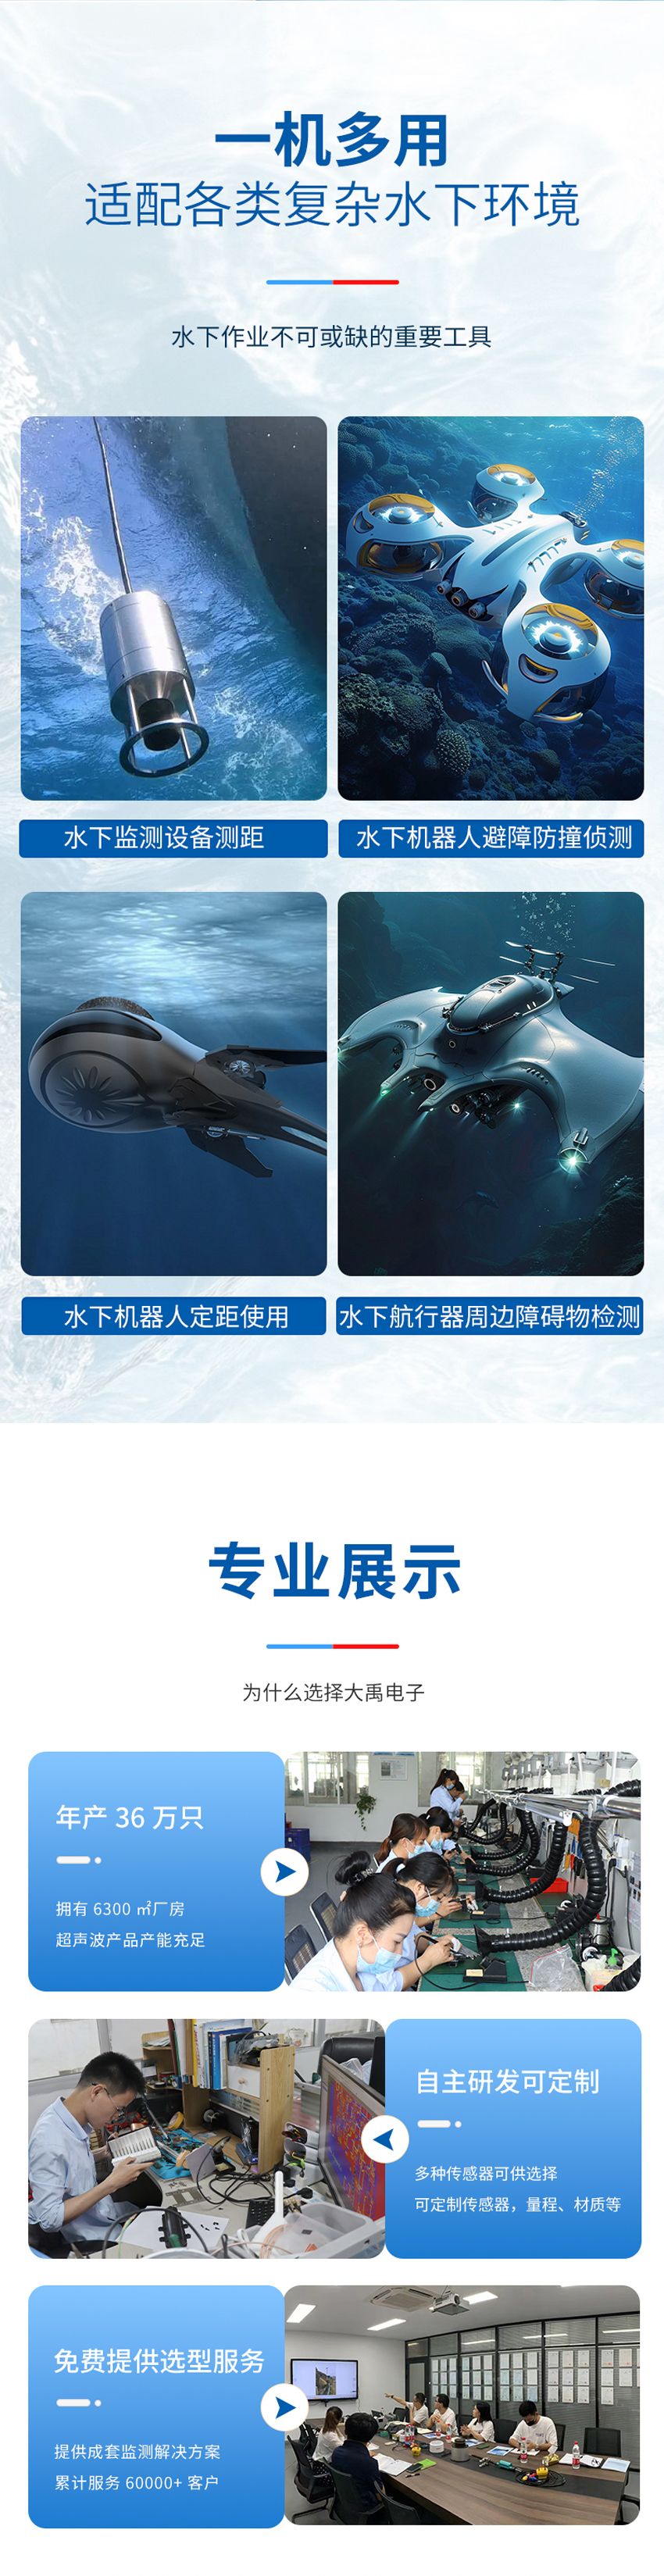
Applications:Obstacle avoidance and anti-collision detection for underwater robots, fixed-distance operation of underwater robots, Subsea pipeline inspection, ranging for underwater monitoring equipment, aquaculture net cages, Reservoir and dam monitoring, surrounding obstacle detection for underwater vehicles
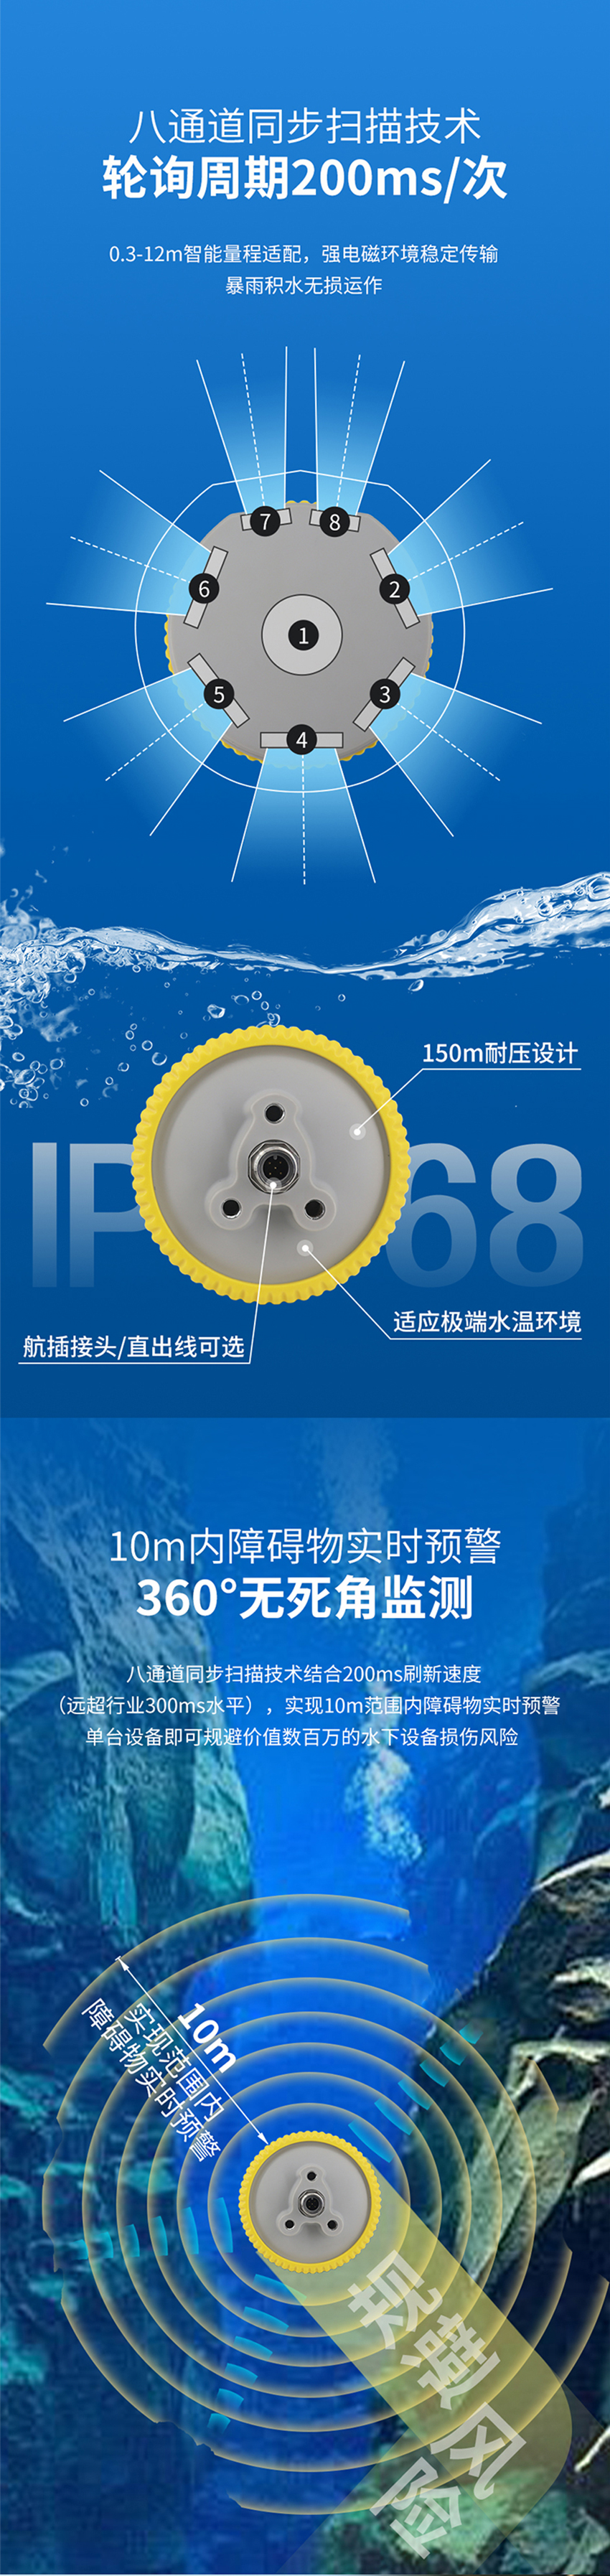
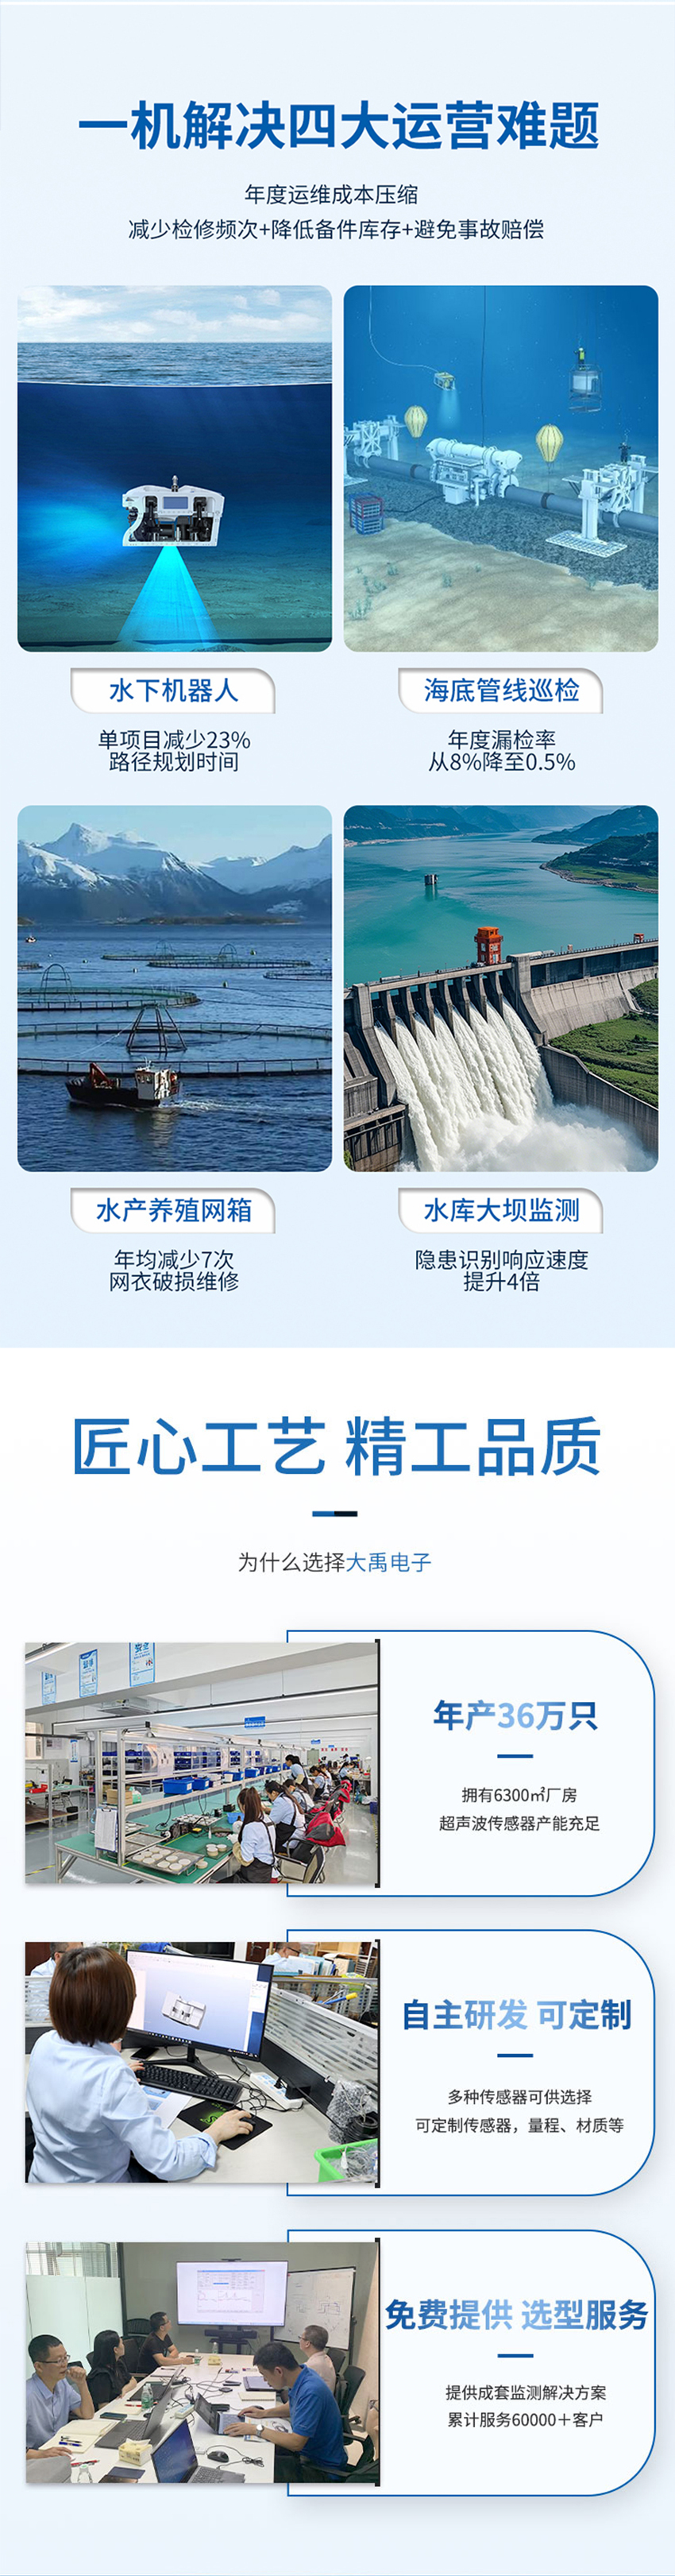
Detection Range:0.2~10m
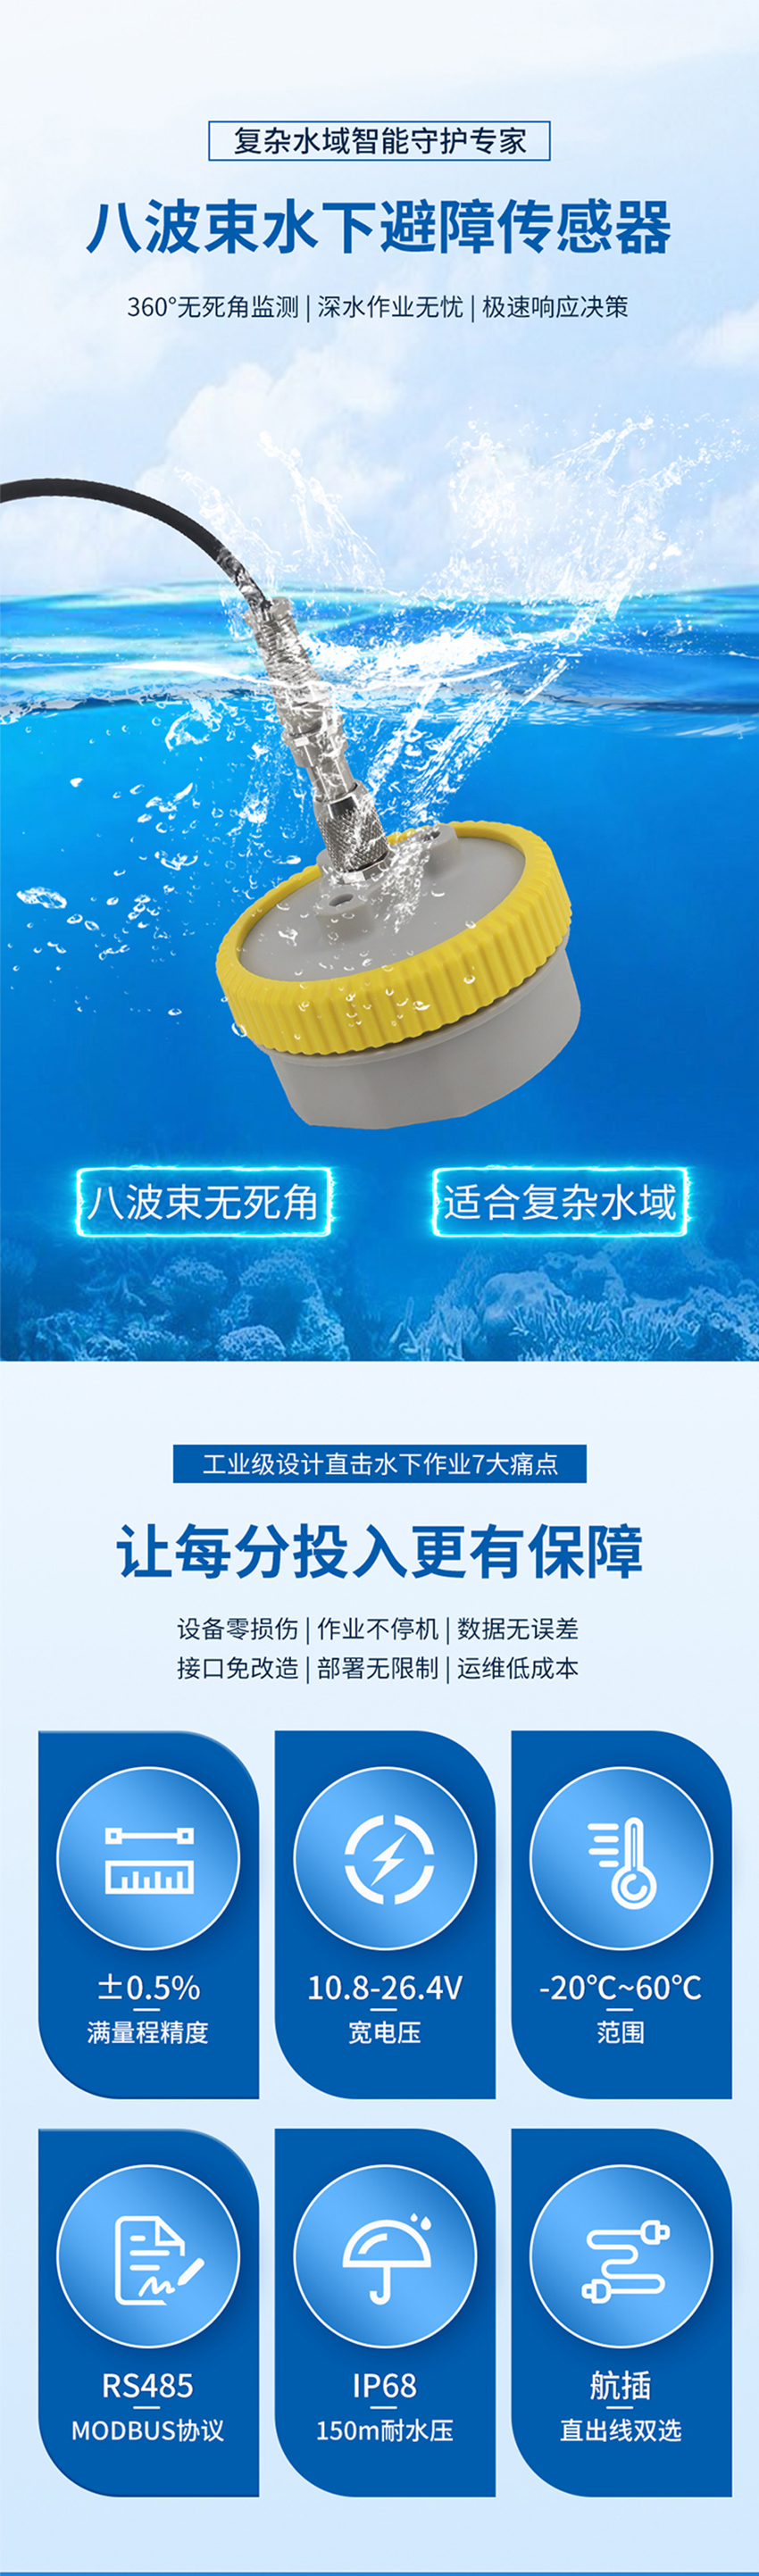
| General parameters | |
|---|---|
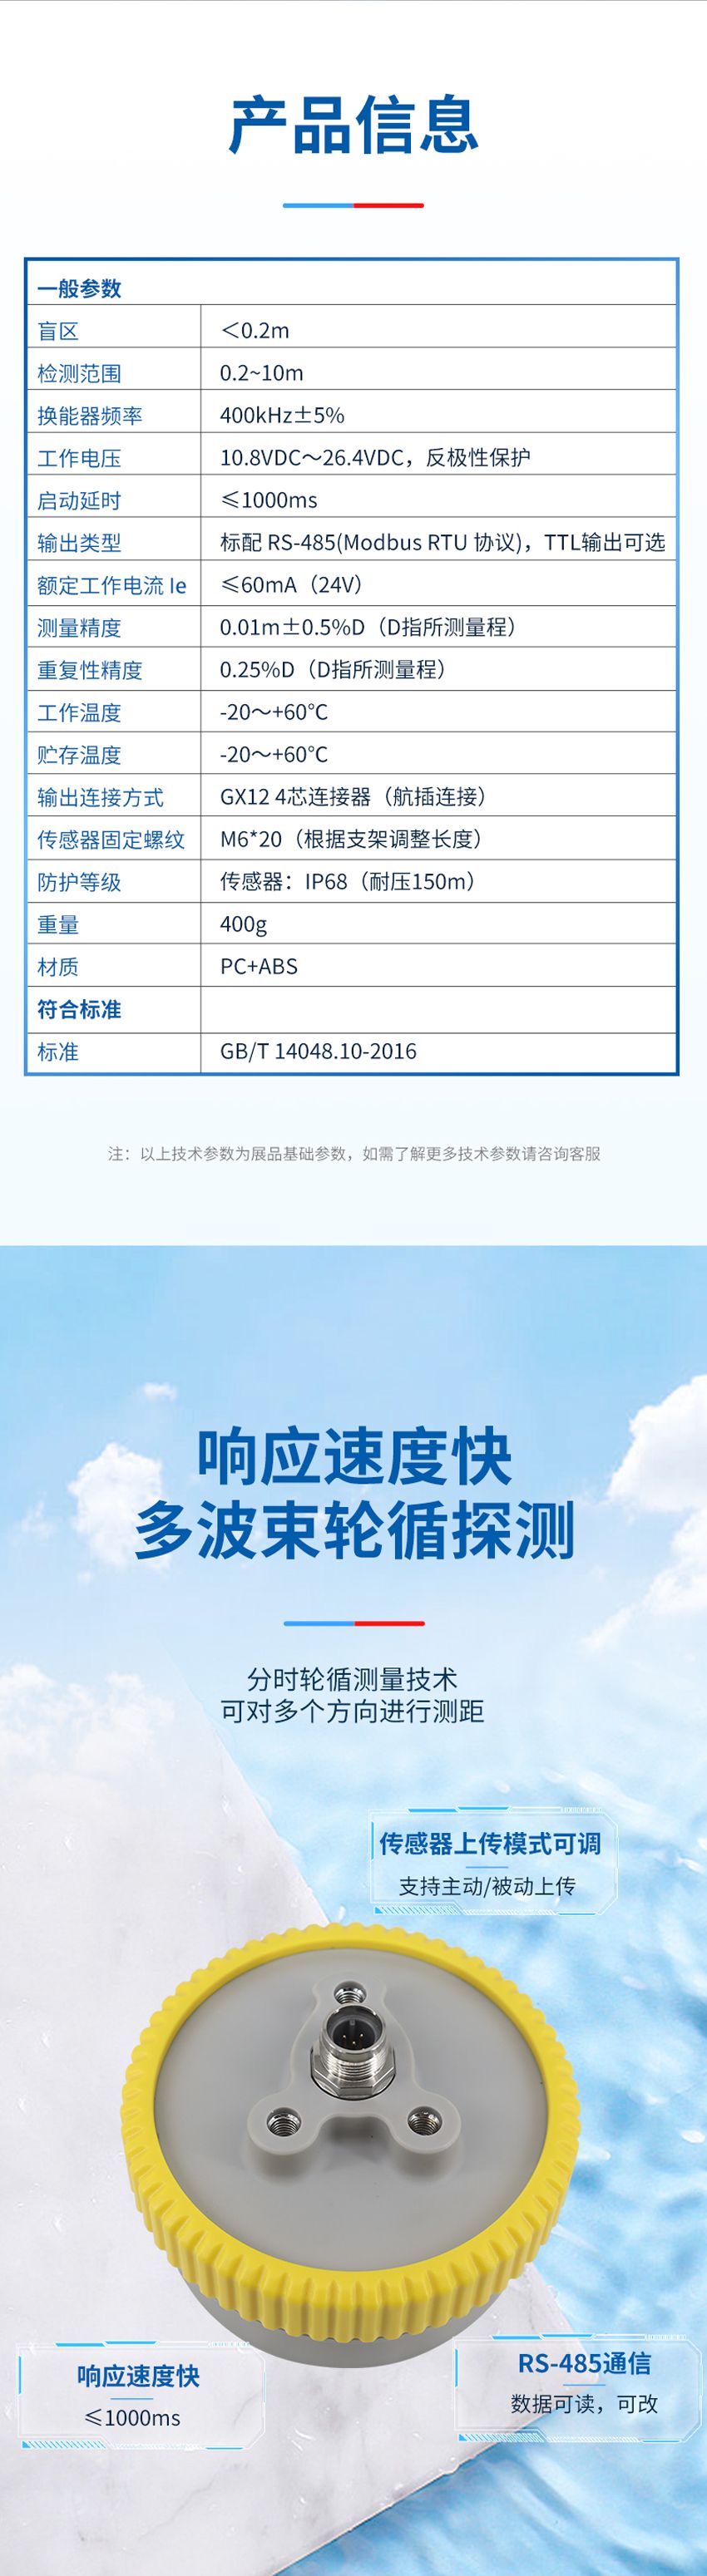
| Blind zone | <0.2 m |
| Detection range | 0.2~10 m |
| Transducer frequency | 400kHz±5% |
| Operating voltage | 10.8VDC~26.4VDC, reverse polarity protection |
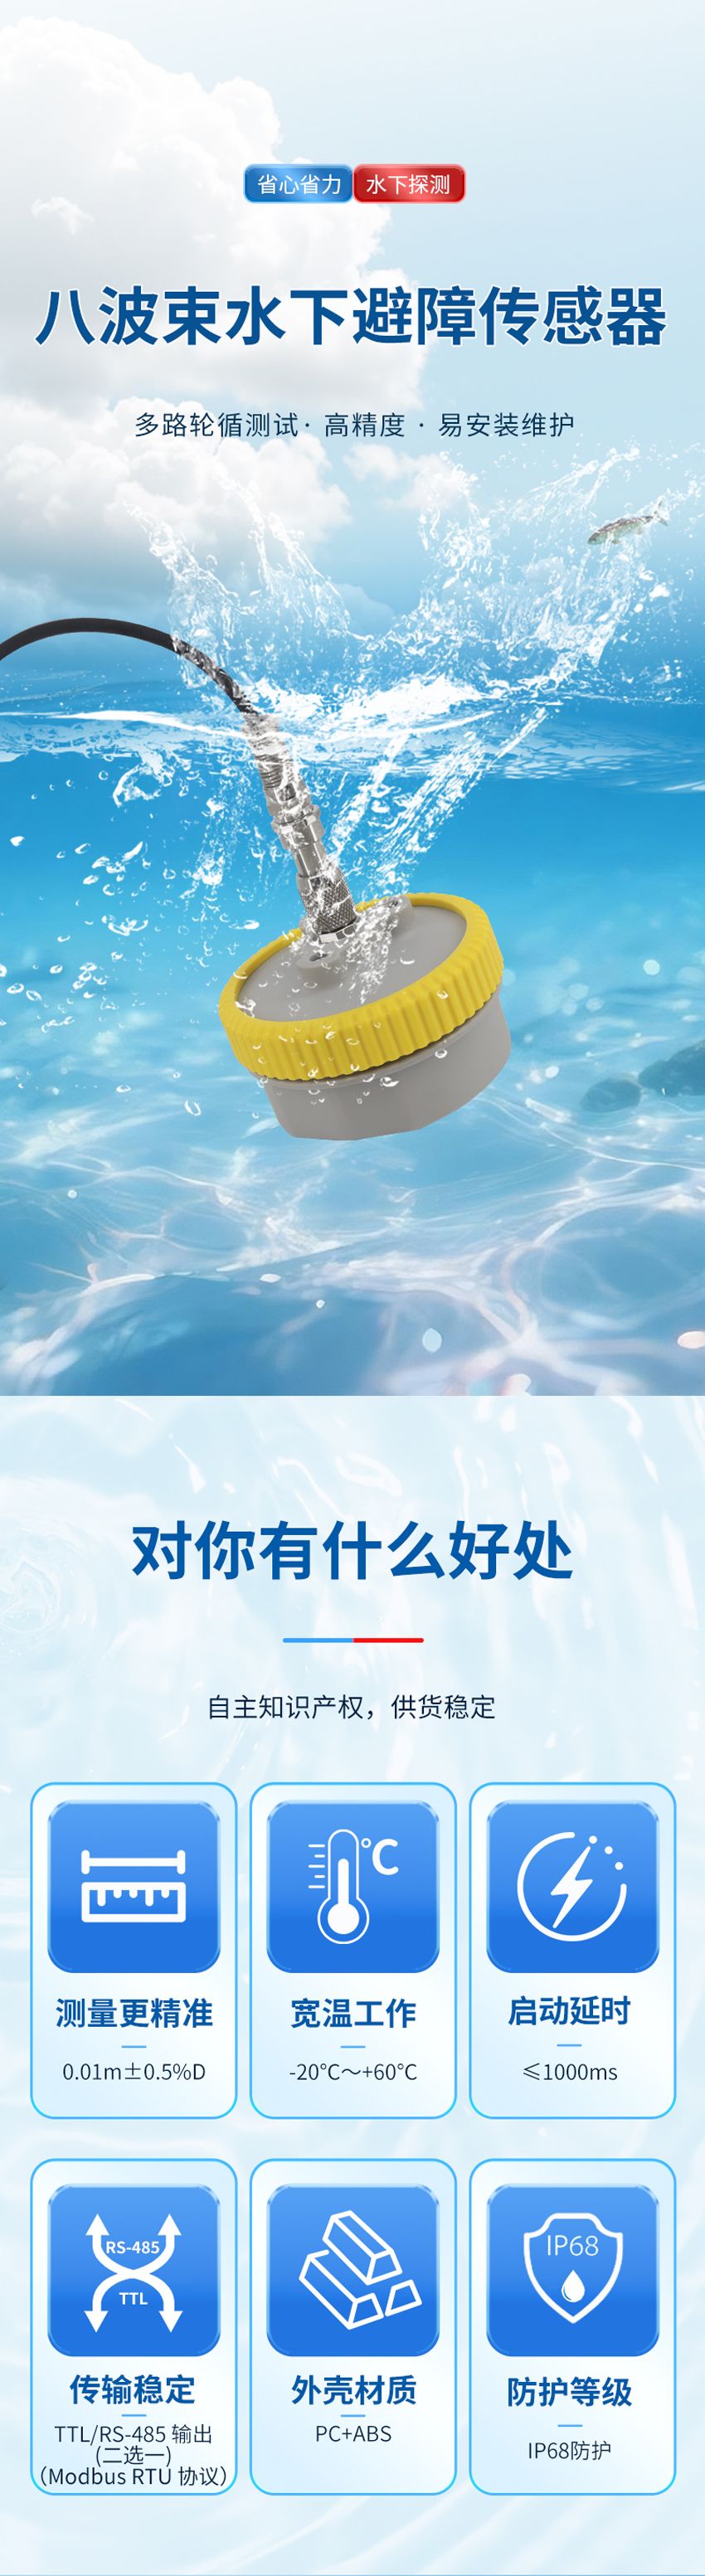
| Start-up delay | ≤1000 ms |
| Output type | Standard RS-485 (Modbus RTU protocol), TTL output optional |
| Rated operating current Ie | ≤60mA(24V) |
| Measurement accuracy | 0.01m±0.5%D (D refers to the measured range) |
| Repeatability accuracy | 0.25%D (D refers to the measured range) |
| Operating temperature | -20~+60 °C |
| Storage temperature | -20~+60 °C |
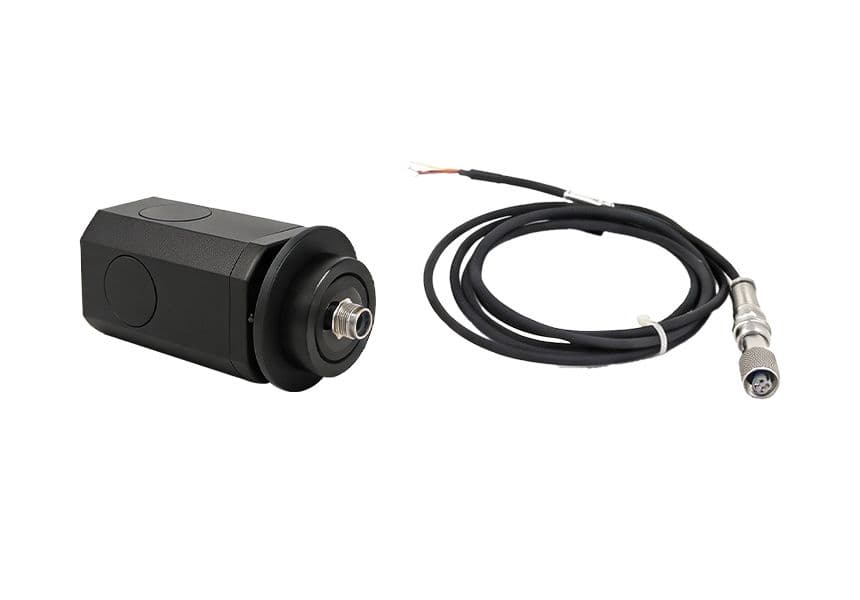
| Output connection method | GX12 4-pin connector (aviation plug connection) |
| Sensor fixing thread | M6*20 (length adjusted according to bracket) |
| Protection rating | Sensor: IP68 (pressure resistant to 150m) |
| Weight | 400 g |
| Material | PC+ABS |
| Compliant standard | |
| Standard | GB/T 14048.10-2016 |
Send us your working conditions — engineers reply with selection advice and pricing within 24 hours.
Online 9:00-18:00 (Mon-Fri)