Tel: 0591-28082552Mob: 18050180580
👤 Login / Register
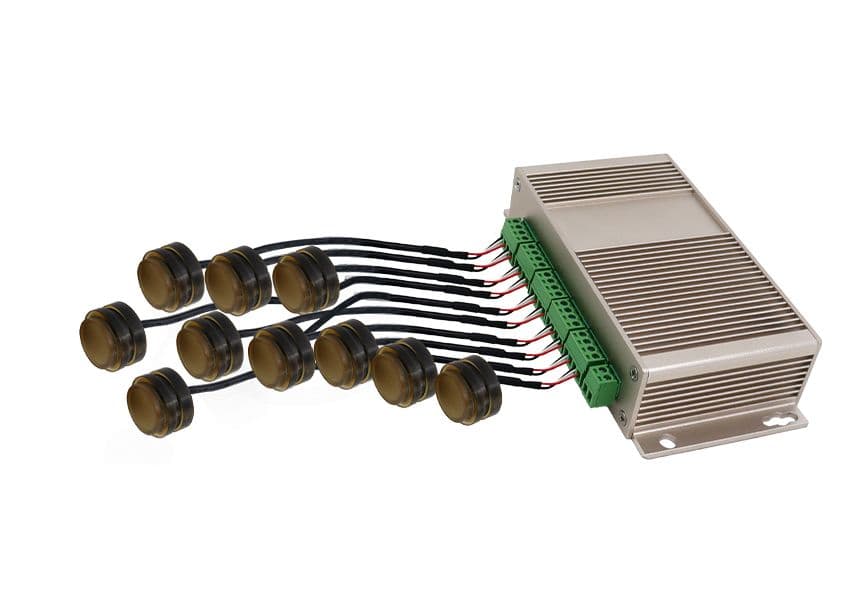
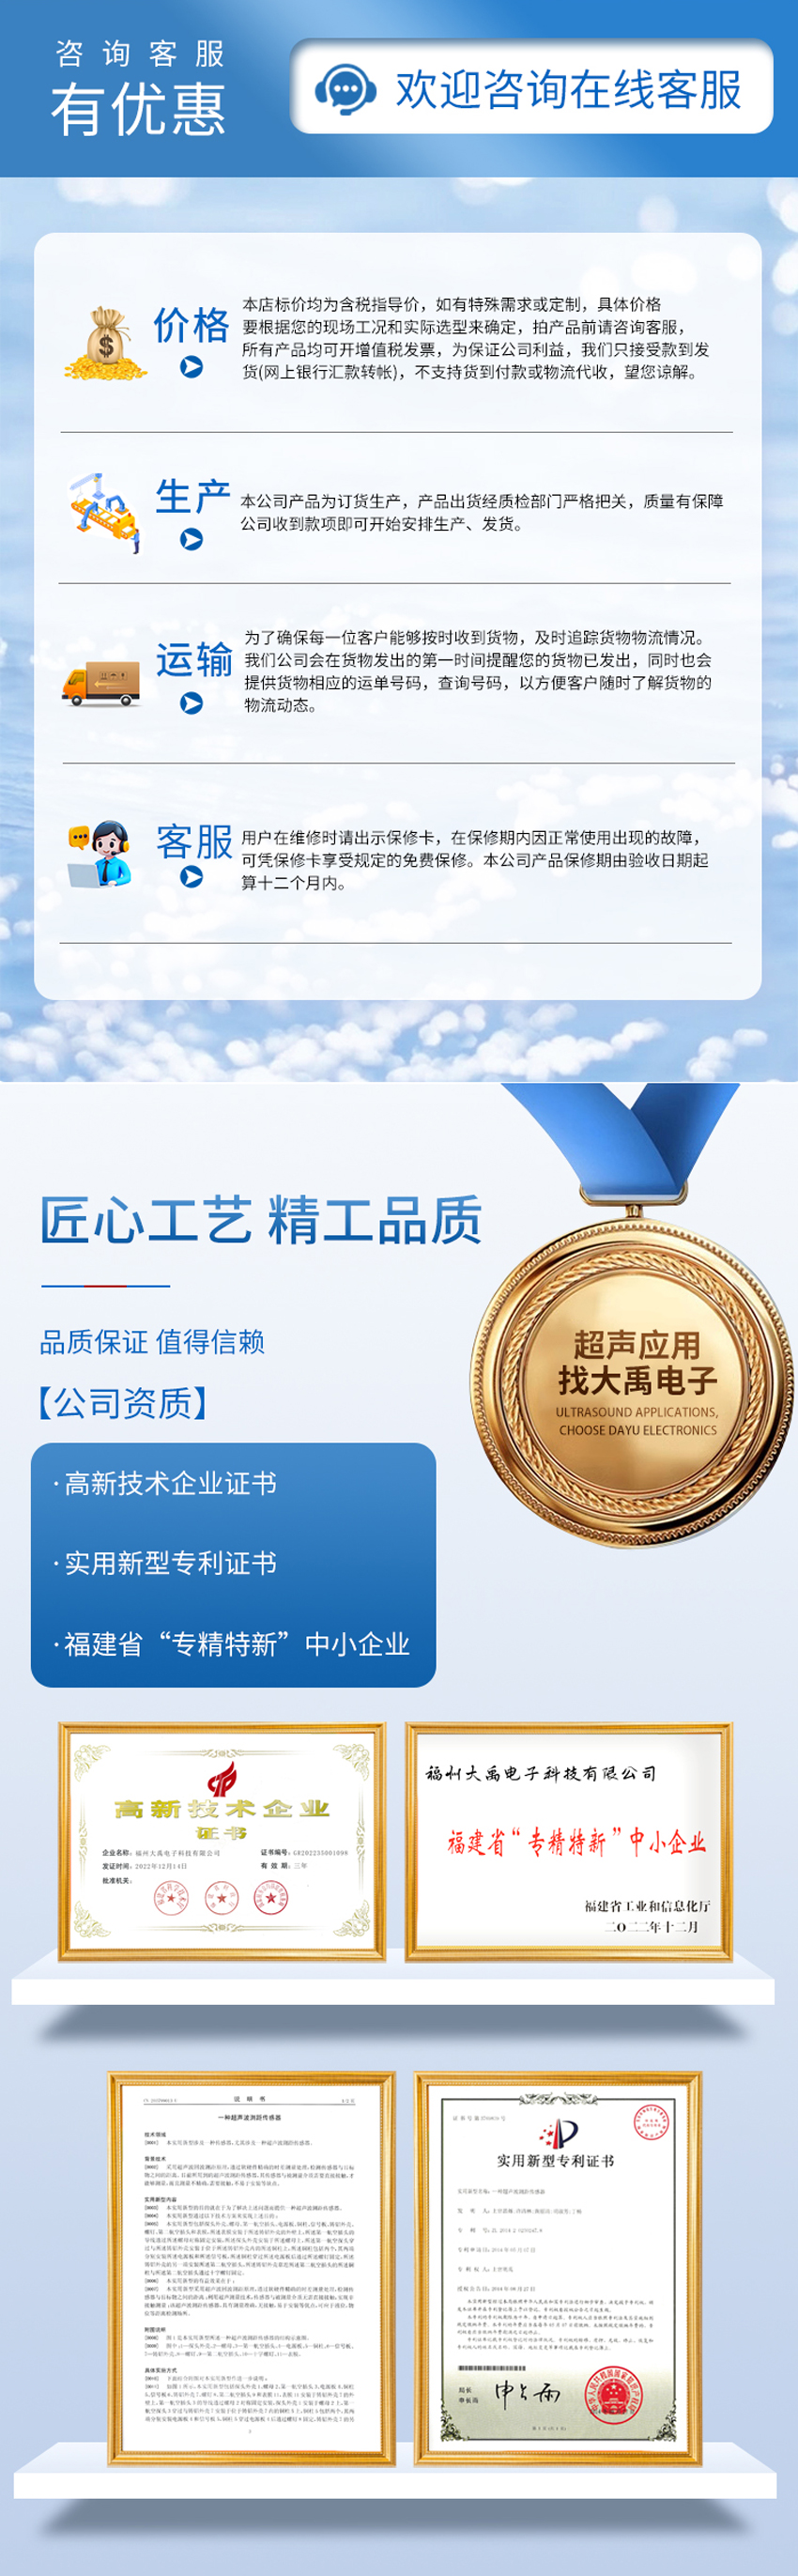
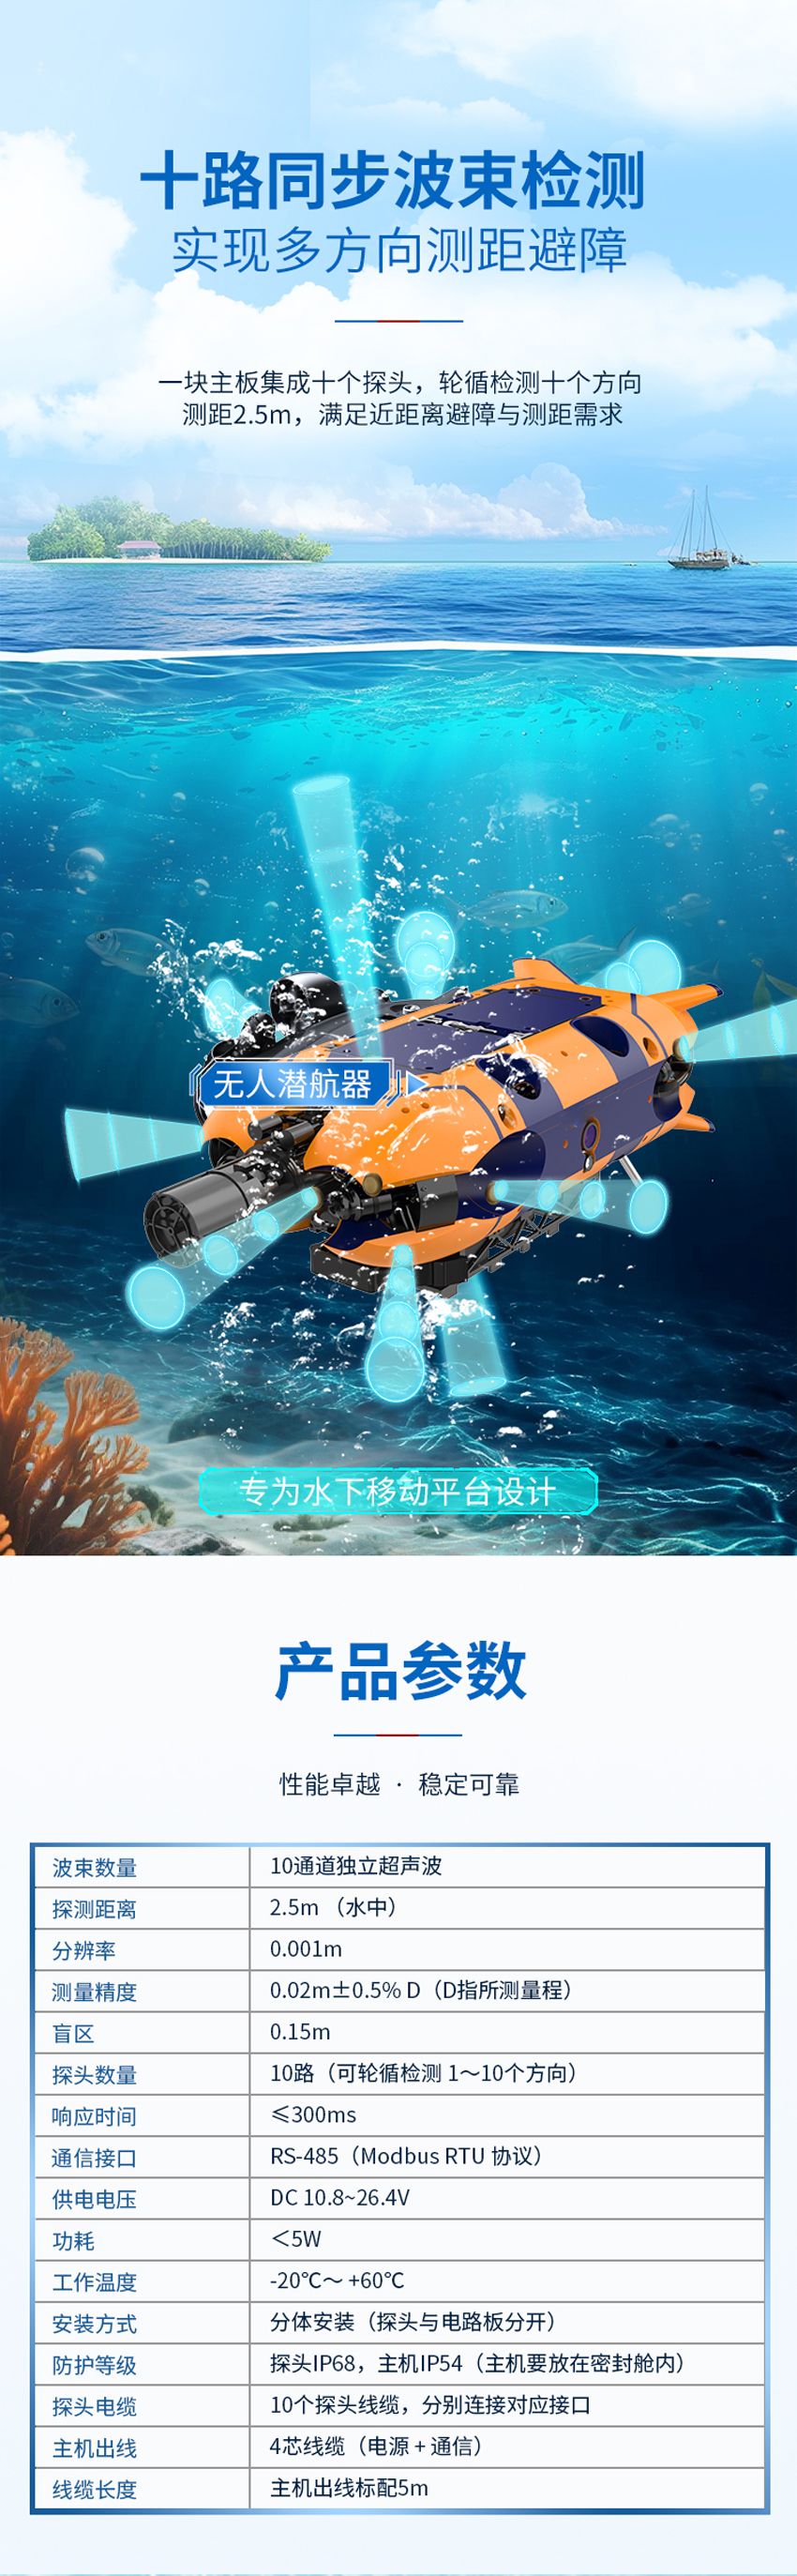
Applications:Underwater ranging for unmanned underwater vehicles, underwater robot obstacle avoidance, Pool cleaning robot obstacle avoidance, underwater ranging for port robots
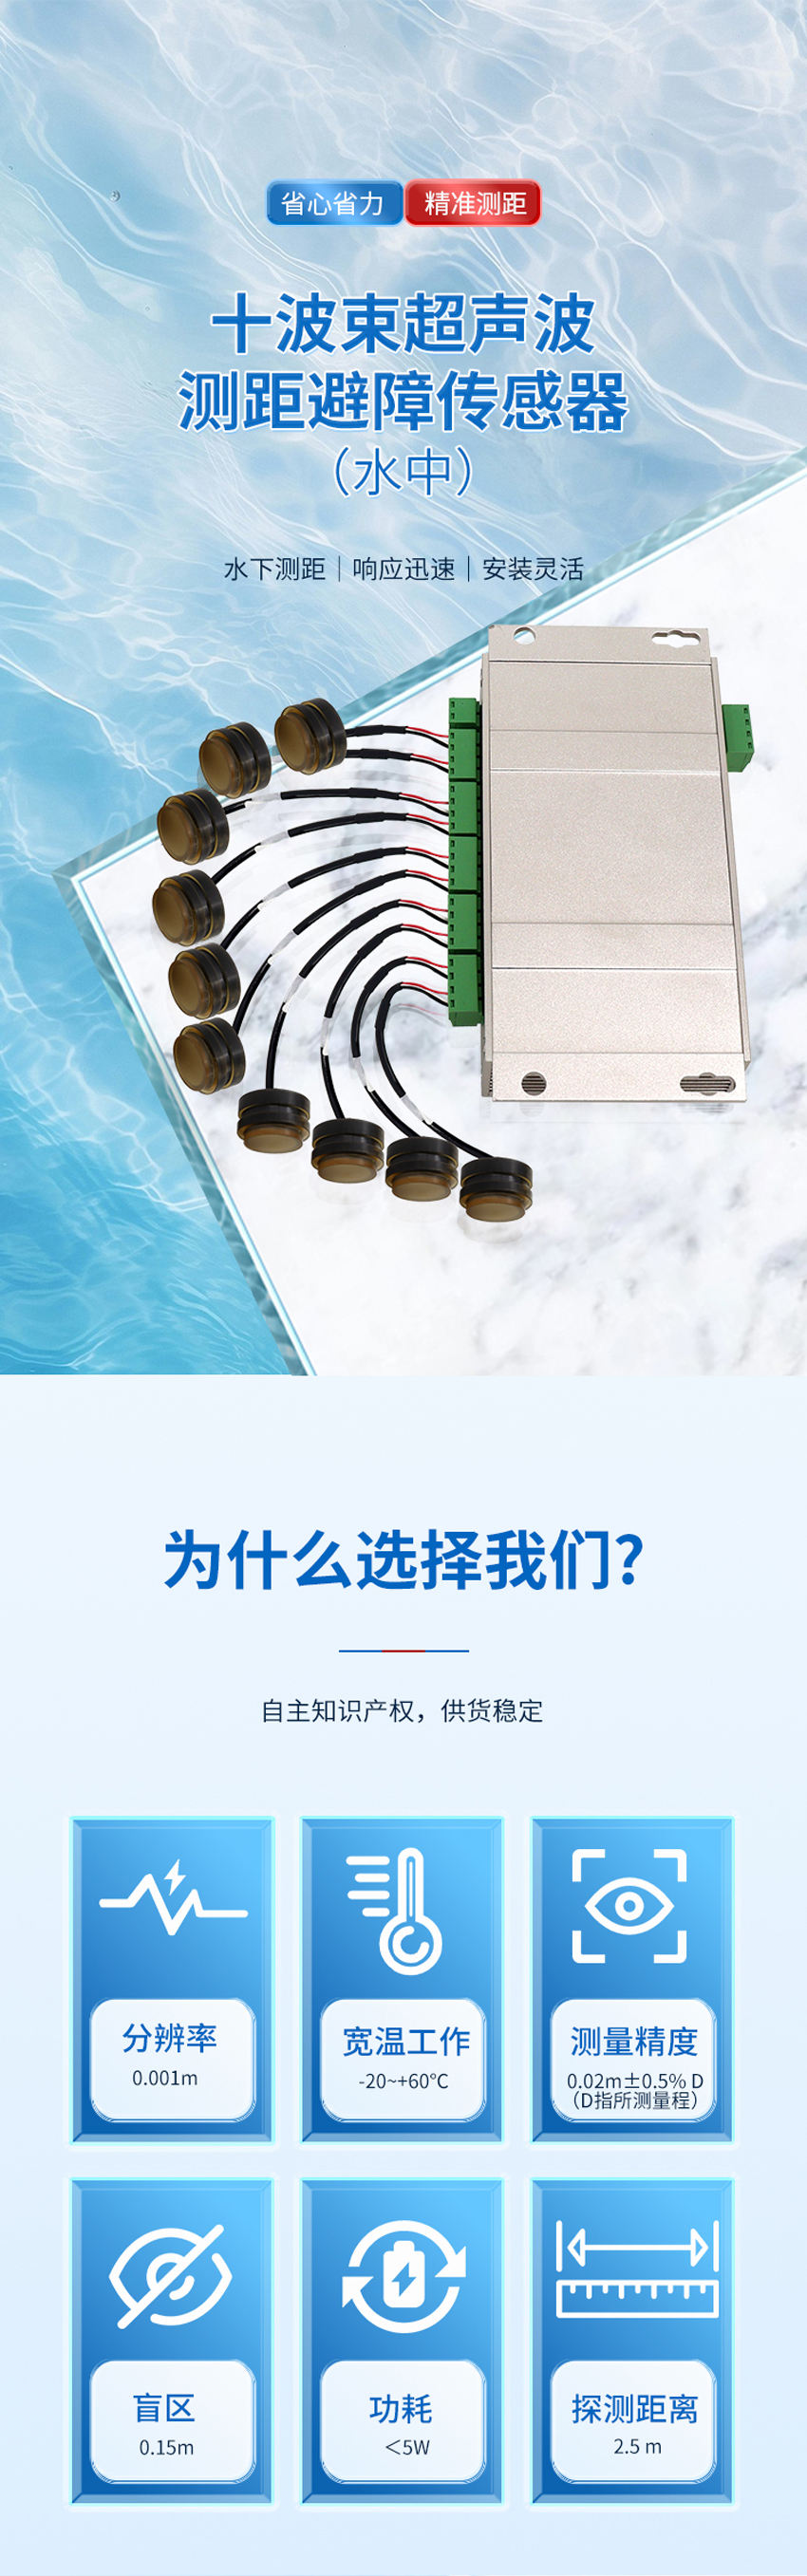
Detection Distance:2.5m (underwater)
Blind Zone:0.15m
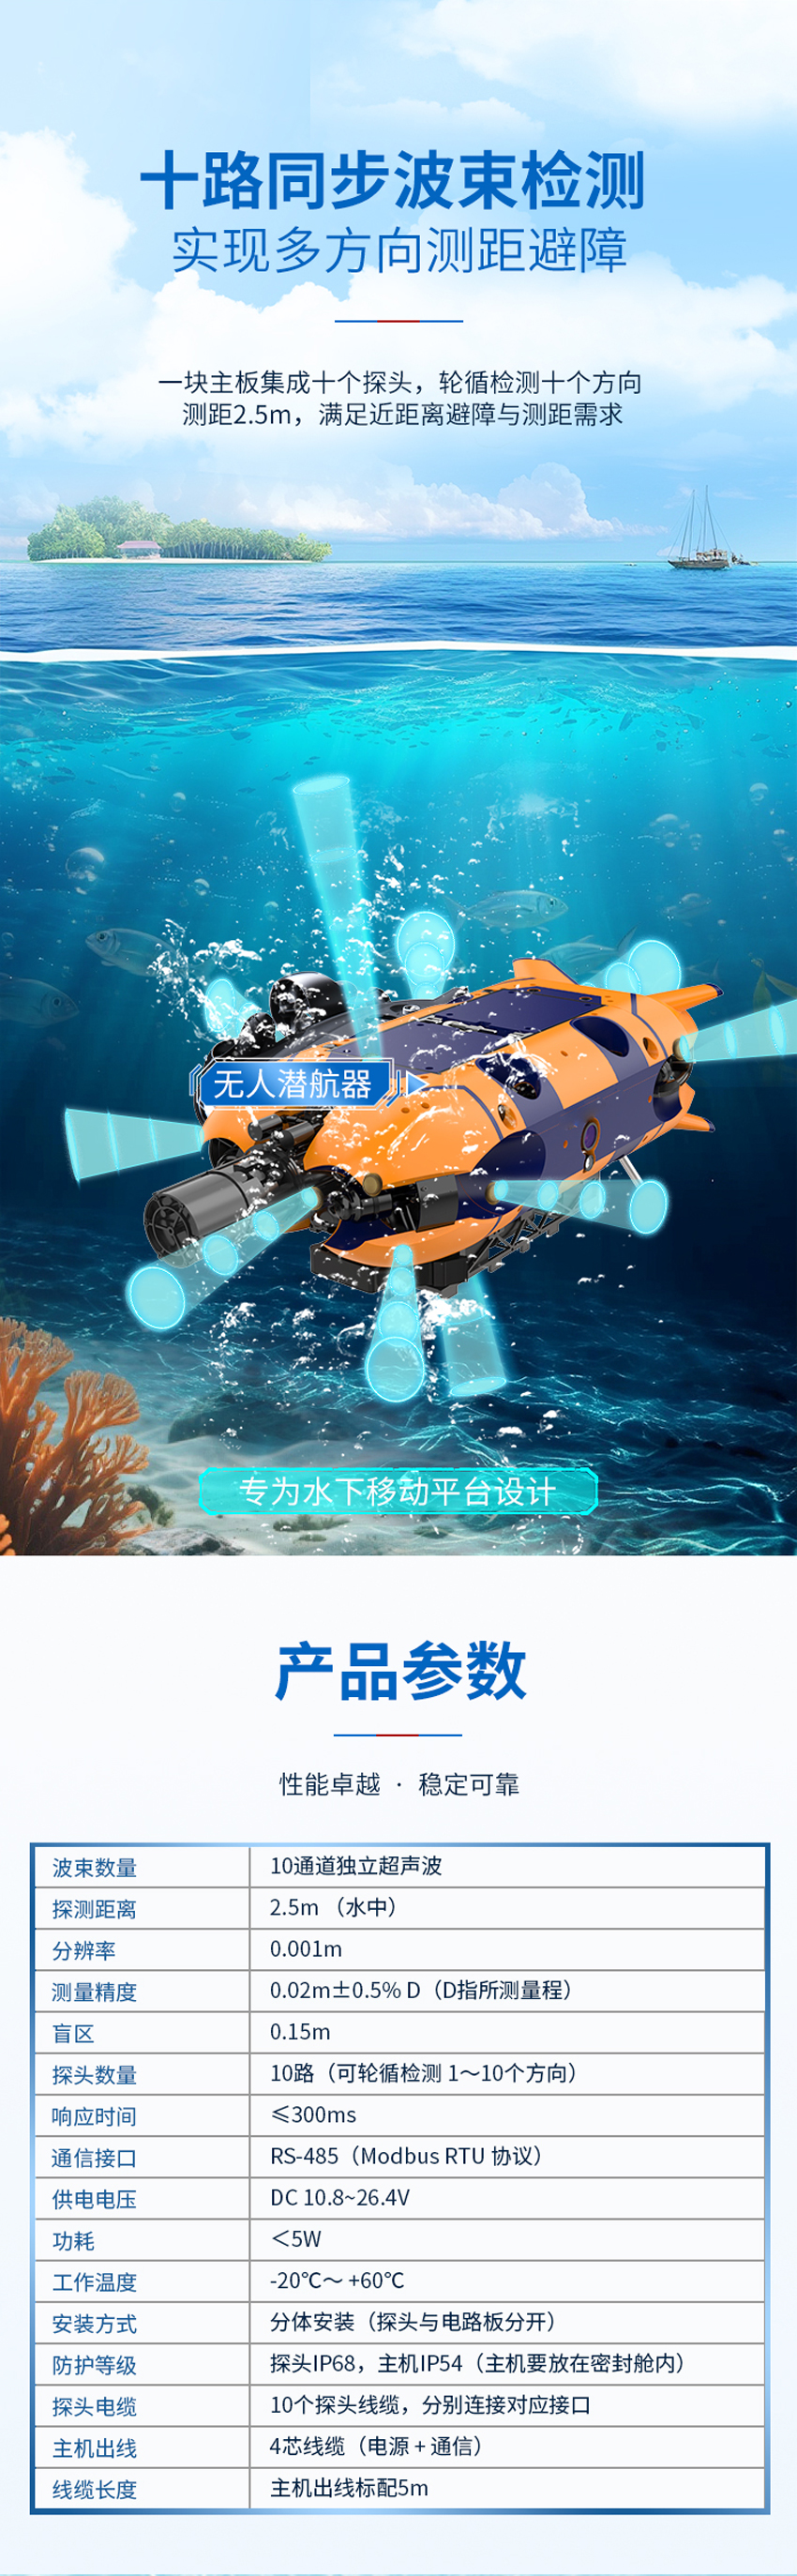
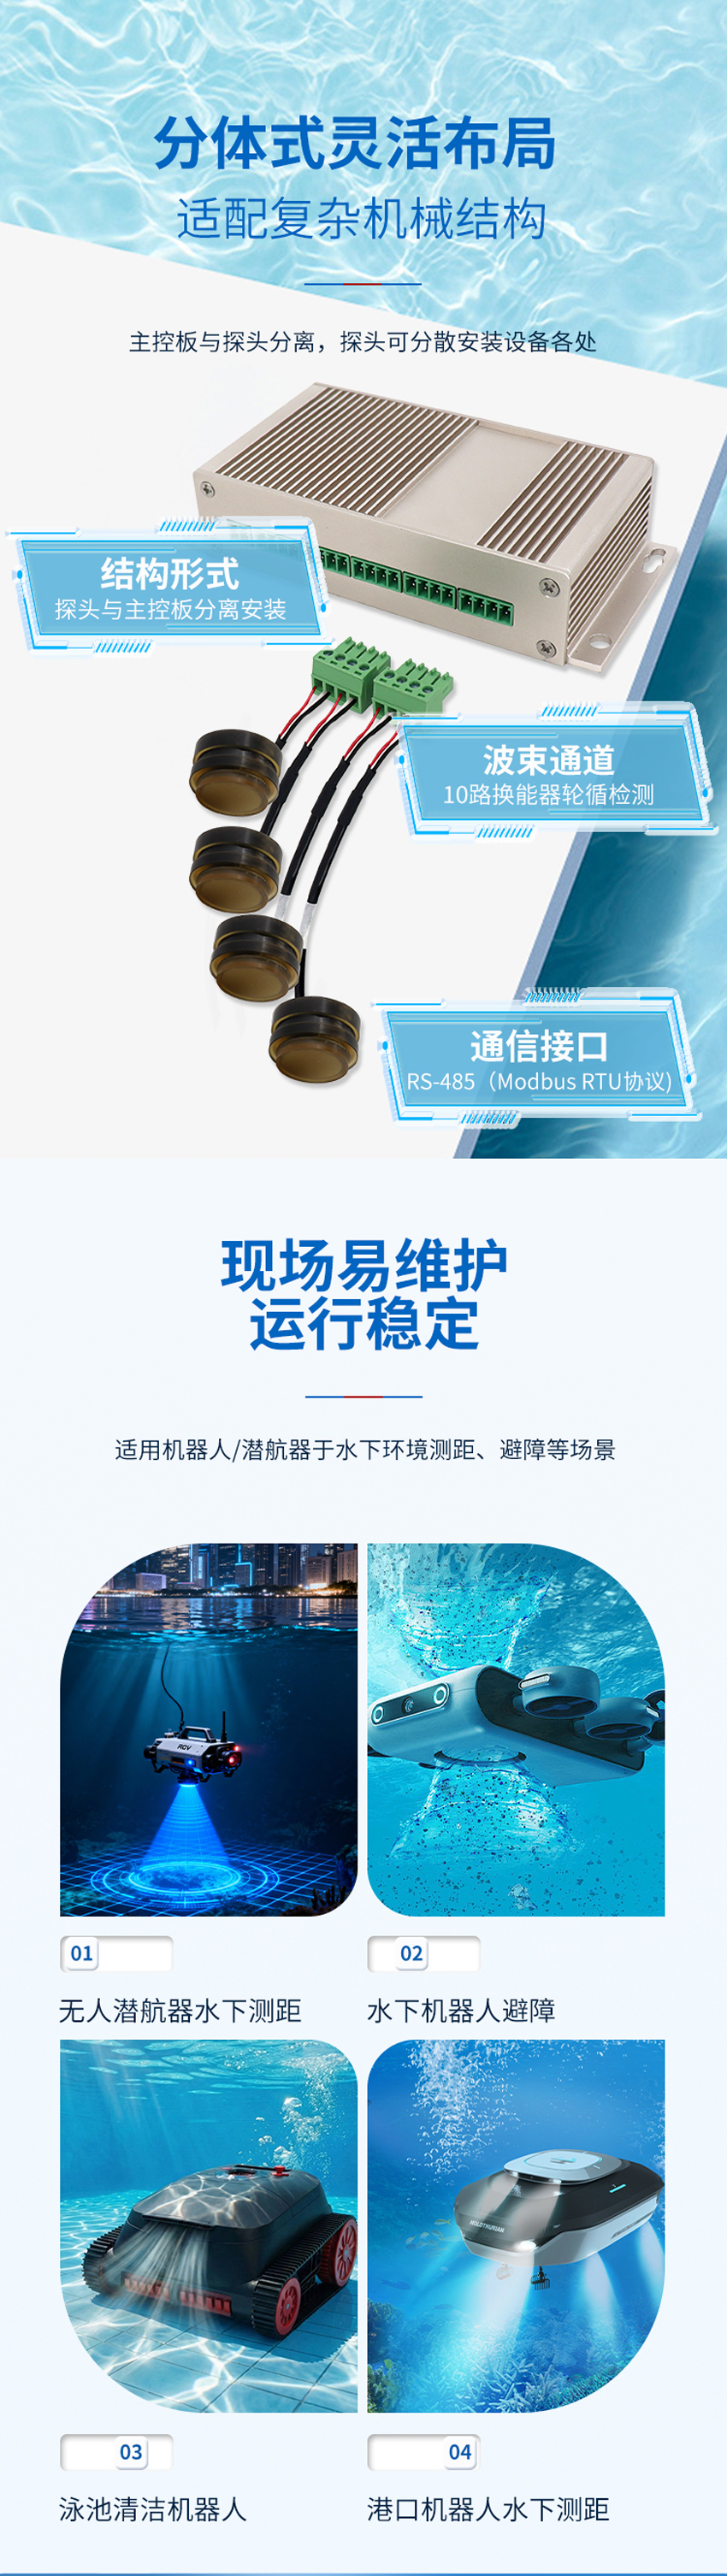
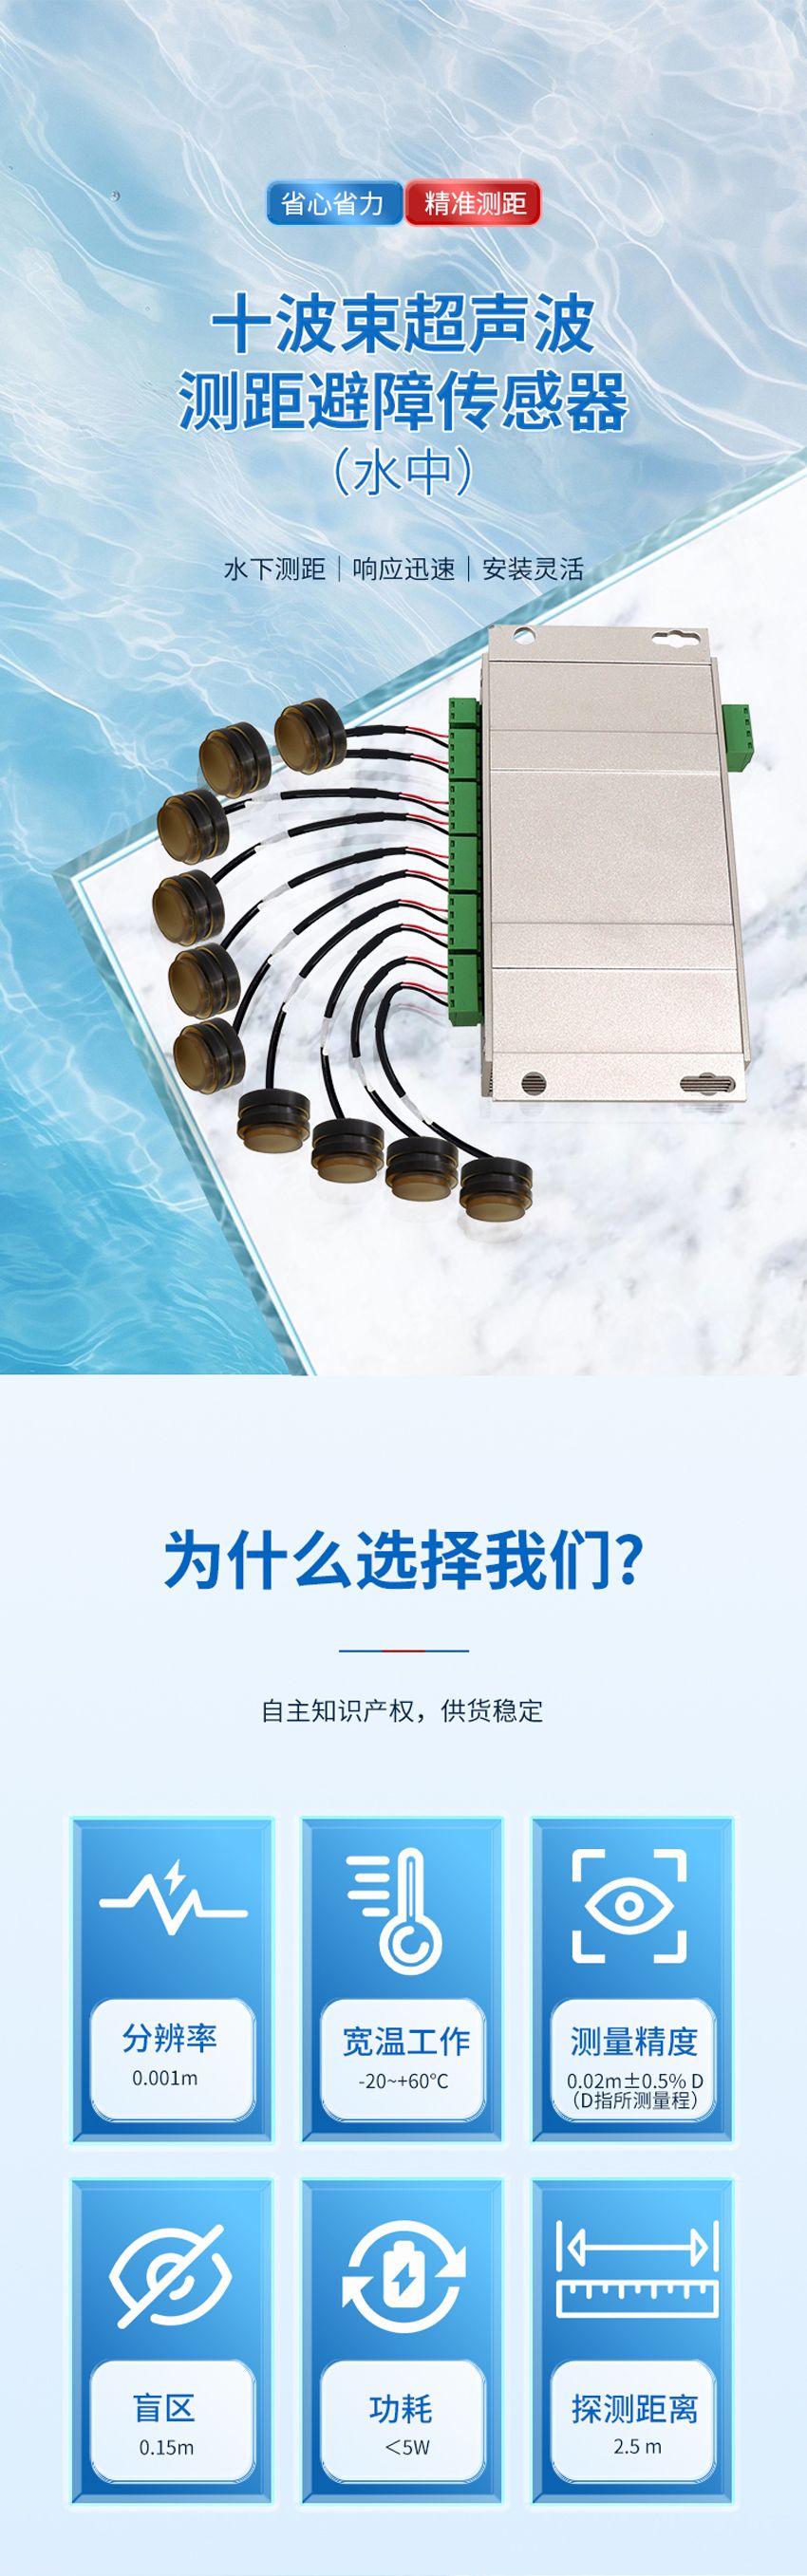
| Number of beams | 10-channel independent ultrasonic |
|---|---|
| Detection distance | 2.5m (in water) |
| Resolution | 0.001 m |
| Measurement accuracy | 0.02m±0.5% D (D refers to the measured range) |
| Blind zone | 0.15 m |
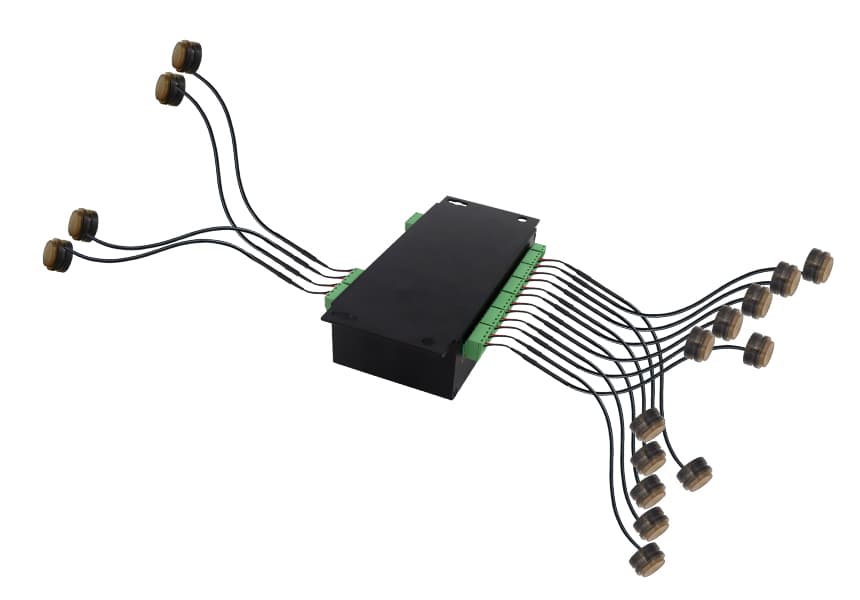
| Number of probes | 10 channels (cyclic detection of 1 to 10 directions) |
| Response time | ≤300 ms |
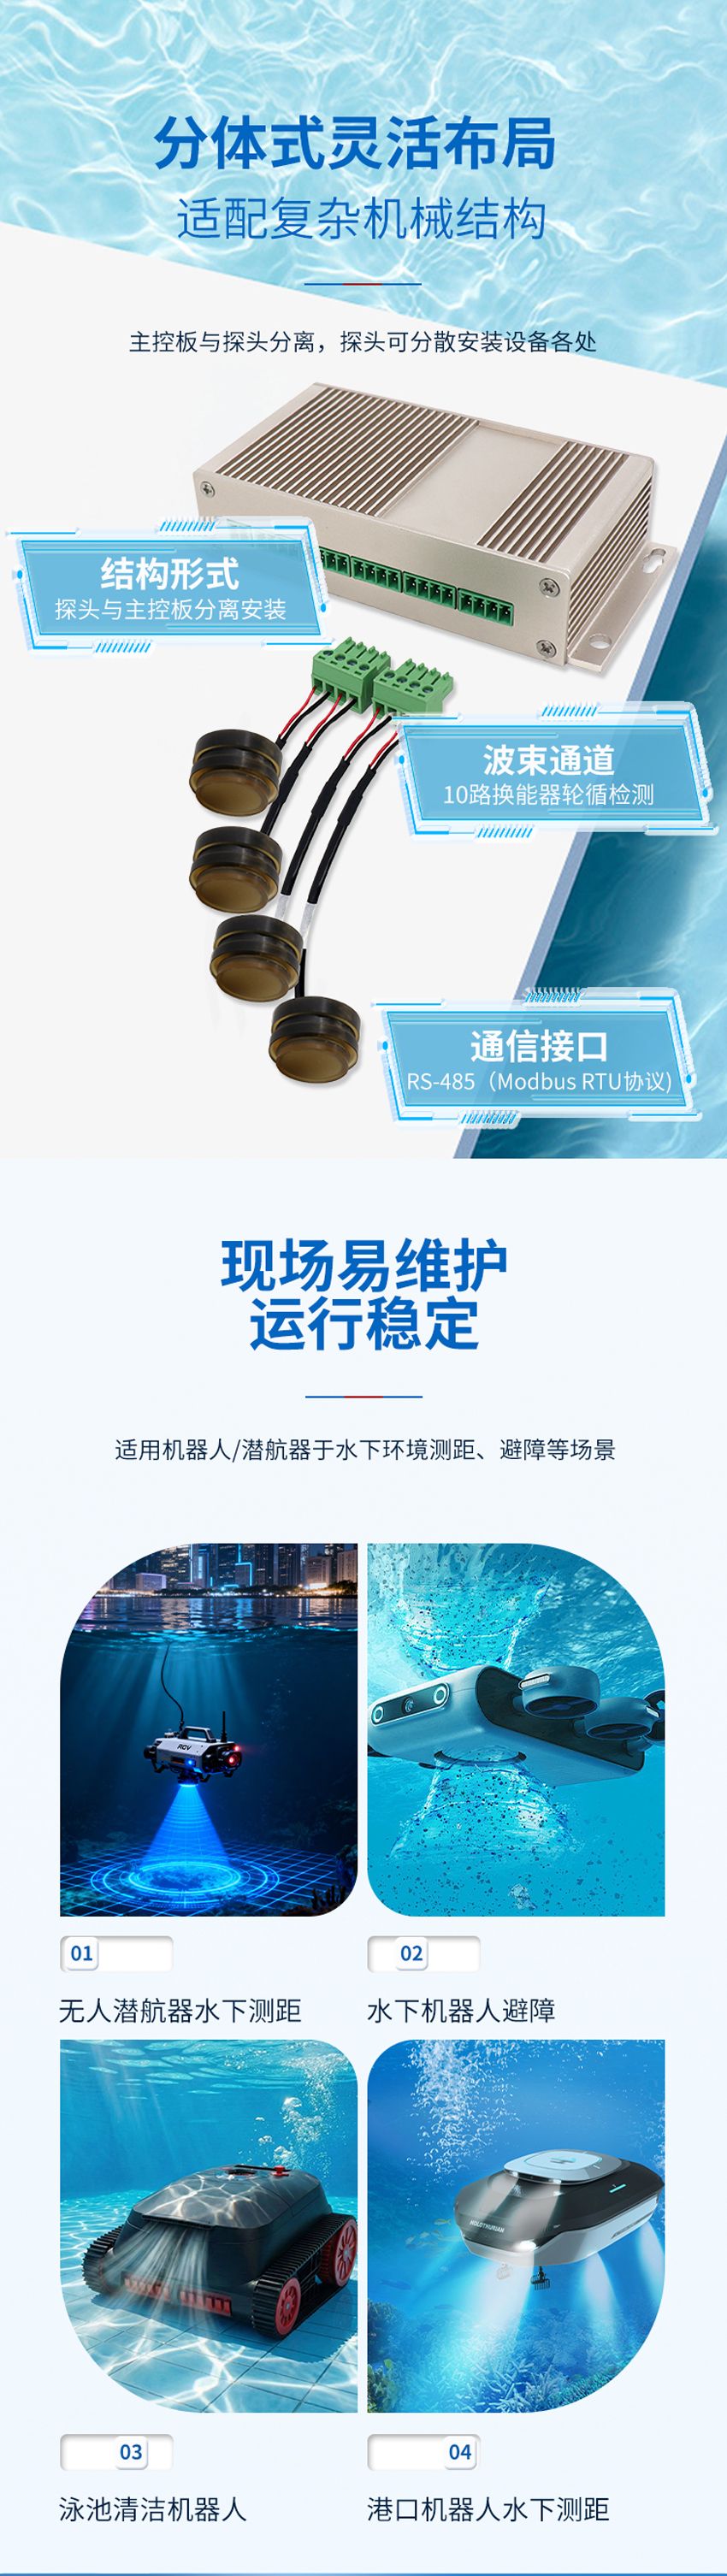
| Communication interface | RS-485 (Modbus RTU protocol) |
| Supply voltage | DC 10.8~26.4 V |
| Power Consumption | <5 W |
| Operating temperature | -20℃~+60 |
| Installation method | Split installation (probe and circuit board separated) |
| Protection rating | Probe IP68, main unit IP54 (main unit must be placed in a sealed compartment) |
| Probe cable | 10 probe cables, connected to corresponding interfaces respectively |
| Main unit outlet cable | 4-core cable (power + communication) |
| Cable length | Main unit outlet cable standard 5 m |
Send us your working conditions — engineers reply with selection advice and pricing within 24 hours.
Online 9:00-18:00 (Mon-Fri)