
Dayu Electronics Underwater Obstacle Avoidance Sensors and Echo Sounder Series[Dayu Electronics]
The Dayu Electronics underwater obstacle avoidance sensor and echo sounder series are underwater single-beam echo ranging devices with all circuitry integrated into the transducer probe. No external circuit board is required—simply power on to measure depth, distance, or scan underwater targets. Measurement data can be output via RS485 (or TTL) serial interface. Featuring compact size, lightweight design, and easy installation, these devices are widely used for depth measurement in lakes or oceans, underwater obstacle avoidance for UUVs or vessels, and mud level measurement in channels or water towers.
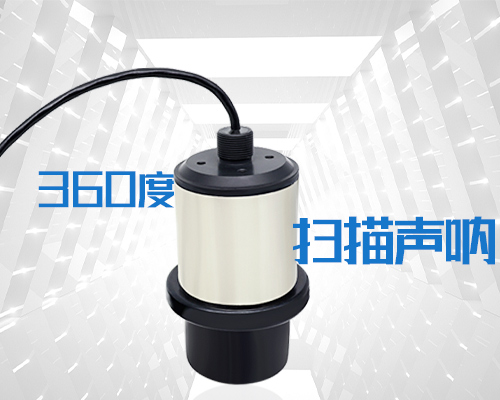
The Dayu Electronics underwater obstacle avoidance sensor and echo sounder series offers two operating modes: echo sounding mode and scanning mode (360° omnidirectional scanning sonar). Echo sounding mode measures distances to the bottom, surface, or obstacles, and with each detection, outputs via the serial interface the distances to the nearest target, strongest target, and farthest target, along with corresponding echo levels, enabling more comprehensive detection data in complex environments for effective target identification.
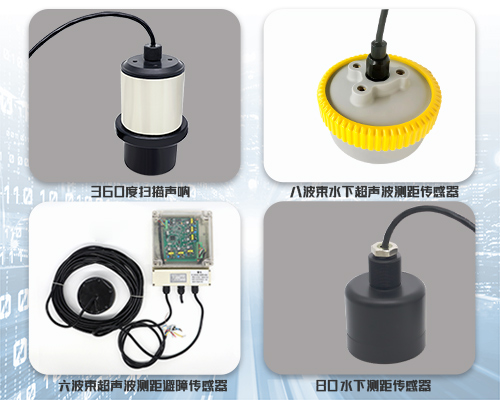
Scanning mode is used for roughly scanning the underwater topography or the distribution of multiple targets in the water. Each detection continuously outputs echo level variations via the serial interface, with a data sampling rate of 500kHz. Currently, it can obtain the specific orientation of external frame structures within the scanning range, and development is underway to achieve detection results similar to imaging sonar.
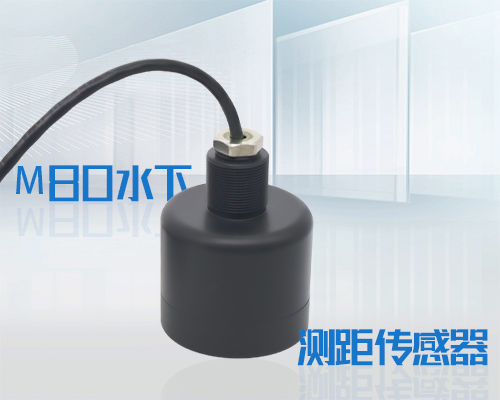
The Dayu Electronics underwater obstacle avoidance sensor and echo sounder series is controlled and data is retrieved via RS485 (or TTL) serial interface. Users can write control programs for the echo sounder based on the serial communication protocol, allowing secondary development to create unique proprietary products.
Additionally, this echo sounder series comes with two sets of display and control software for Windows systems. One set is used for ranging mode, enabling continuous measurement, recording, and display of water depth (or obstacle distance) over time. The other set is for scanning mode, allowing continuous scanning, recording, and display of approximate underwater topography or distribution of multiple targets in the water.