
Underwater Distance Sensor Measurement Considerations - [Dayu Electronics]
Underwater distance sensor stability can be improved; however, readings of 0 are common during measurement for the following reasons:
First: The installation location of the underwater distance sensor at the bottom of the vessel.
1. It must be positioned away from the water flow that propels the vessel forward.
If the vessel is propeller-driven, the sensor must not be placed in the water flow generated by the rotating propeller.
If the vessel is waterjet-driven, the sensor must not be placed in the water flow exiting the waterjet nozzle.
2. Sensor submersion depth
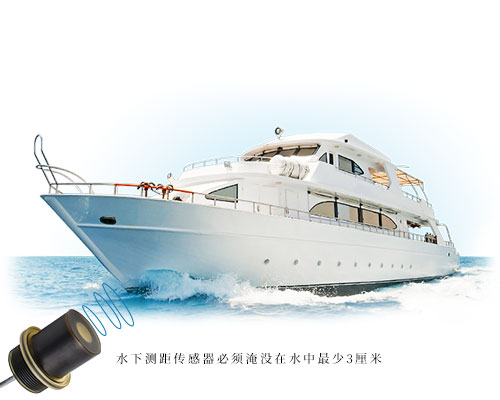
During vessel operation, the underwater distance sensor must be submerged in water to a depth of at least 3 cm.
Second: Electromagnetic interference
1. If the vessel is propelled by a diesel engine, significant electromagnetic interference can be introduced into the power supply.
2. If the vessel is battery-powered, after the electric motor starts, significant electromagnetic interference can also be introduced into the power supply.
Solution: Add an isolated DC-DC converter to the sensor's power input section to isolate electromagnetic interference from the power supply.
Third: Degree of vessel pitching during operation
During vessel operation, the higher the speed, the greater the vessel's pitching angle.
During vessel operation, the larger the waves, the greater the vessel's pitching angle.
When the pitching angle exceeds the maximum allowable range of the underwater distance sensor, the measurement data will read 0.
Fourth: Vessel speed and measurement frequency When the water depth is 10 meters or less,
It has been verified that at vessel speeds ≤ 2.0 m/s, the underwater distance sensor can measure normally at a rate of 5 times per second.
When the vessel speed exceeds 2.0 m/s, the underwater distance sensor must measure at a rate of 10 times per second or faster.
If the measurement speed is insufficient, the underwater distance sensor may not receive the reflected ultrasonic echo, resulting in a reading of 0.