
Hydrophone vs. Transducer: Core Differences and Application Boundaries [Dayu Electronics]
In the fields of acoustic testing and underwater acoustic engineering, hydrophones and transducers are two core devices. They share a subordinate relationship (one is contained within the other) and differ significantly in functional positioning, operating modes, and technical parameters, jointly supporting the transmission and reception chain of underwater acoustic signals.
1. Definitions and Core Functional Boundaries
A transducer is a general-purpose energy conversion device, with the core function of achieving bidirectional conversion between electrical energy and acoustic energy. It can be divided into transmitting, receiving, and combined transmitting-receiving types, and is widely used in scenarios such as ultrasonic testing and underwater acoustic detection, serving as the basic execution unit of acoustic systems. A hydrophone, on the other hand, is a special subclass of transducer, specifically referring to a receiving-type transducer dedicated to underwater use. It is only responsible for converting acoustic pressure signals in water into electrical signals and does not have the capability to actively transmit sound waves. It is equivalent to an underwater 'microphone,' specializing in passively receiving acoustic field information.
2. Working Principles and Performance Focus
Both devices are based on the piezoelectric effect or magnetostrictive effect, but their performance design directions are completely different. In transmitting mode, a transducer converts electrical pulses into high-intensity sound waves through the inverse piezoelectric effect, emphasizing high-power, high-efficiency energy radiation capability. In receiving mode, it receives echoes through the direct piezoelectric effect, balancing sensitivity and bandwidth. A hydrophone only needs to perform acoustic-to-electrical conversion, and its design focuses on ultra-high sensitivity, capable of capturing weak acoustic pressure signals at the μPa level, with a wide frequency response and low noise. It is often paired with a preamplifier to improve the signal-to-noise ratio and prevent signal distortion.
3. Differences in Application Scenarios and Structural Design
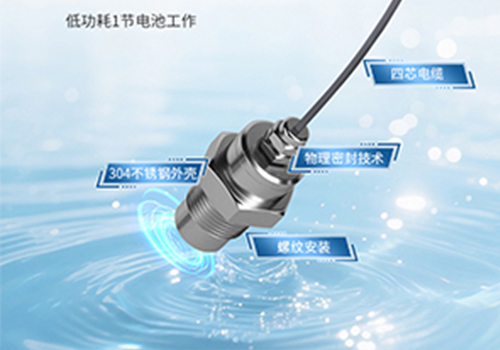
Transducers are suitable for active detection scenarios, such as target positioning in sonar systems and defect imaging in ultrasonic testing. Their structure must accommodate both transmitting power and receiving efficiency, with common combined transmitting-receiving array element designs. Hydrophones are primarily used for passive monitoring, such as ocean ambient noise collection and underwater target acoustic signal interception. Structurally, they emphasize waterproof sealing and acoustic matching, often using sensitive materials like piezoelectric ceramics and optical fibers. Some vector hydrophones can simultaneously measure acoustic pressure and particle velocity, enabling sound source direction finding.
4. Key Parameters and Calibration Requirements
Key parameters for transducers include transmitting power, electro-acoustic efficiency, and directivity, which require calibration for both transmitting and receiving performance. Hydrophones, on the other hand, focus on receiving sensitivity, equivalent noise pressure level, and frequency response. Calibration centers on the accuracy of sound pressure-to-voltage conversion to ensure precise capture of weak signals.
In summary, a hydrophone is a specialized form of transducer for underwater receiving scenarios. The core differences between the two lie in functional specificity and performance priorities, together forming a complete technical system for underwater acoustic detection.